Loading...
Searching...
No Matches
BIORBD_NAMESPACE::internal_forces::muscles::MuscleGeometry Class Reference
Class muscle geometry of the muscle. More...
#include <MuscleGeometry.h>
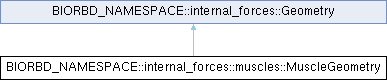
Inheritance diagram for BIORBD_NAMESPACE::internal_forces::muscles::MuscleGeometry:
Public Member Functions | |
| MuscleGeometry () | |
| Construct muscle geometry. | |
| MuscleGeometry (const utils::Vector3d &origin, const utils::Vector3d &insertion) | |
| Construct muscle geometry. | |
| MuscleGeometry | DeepCopy () const |
| Deep copy of a muscle geometry. | |
| void | DeepCopy (const MuscleGeometry &other) |
| Deep copy of a muscle geometry from another muscle geometry. | |
| void | updateKinematics (rigidbody::Joints &updatedModel, const Characteristics &characteristics, const rigidbody::GeneralizedCoordinates *Q=nullptr, const rigidbody::GeneralizedVelocity *Qdot=nullptr) |
| Updates the position and dynamic elements of the muscles. | |
| void | updateKinematics (rigidbody::Joints &updatedModel, const Characteristics &characteristics, internal_forces::PathModifiers &pathModifiers, const rigidbody::GeneralizedCoordinates *Q=nullptr, const rigidbody::GeneralizedVelocity *Qdot=nullptr) |
| Updates the position and dynamic elements of the muscles. | |
| void | updateKinematics (std::vector< utils::Vector3d > &musclePointsInGlobal, utils::Matrix &jacoPointsInGlobal, const Characteristics &characteristics, const rigidbody::GeneralizedVelocity *Qdot=nullptr) |
| Updates the position and dynamic elements of the muscles by hand. | |
| const utils::Scalar & | length () const |
| Return the previously computed muscle length. | |
| const utils::Scalar & | musculoTendonLength () const |
| Return the previously computed muscle tendon length. | |
| Public Member Functions inherited from BIORBD_NAMESPACE::internal_forces::Geometry | |
| Geometry () | |
| Construct geometry. | |
| Geometry (const utils::Vector3d &origin, const utils::Vector3d &insertion) | |
| Construct geometry. | |
| Geometry | DeepCopy () const |
| Deep copy of a geometry. | |
| void | DeepCopy (const Geometry &other) |
| Deep copy of a geometry from another geometry. | |
| void | updateKinematics (rigidbody::Joints &updatedModel, const rigidbody::GeneralizedCoordinates *Q=nullptr, const rigidbody::GeneralizedVelocity *Qdot=nullptr) |
| Updates the position and dynamic elements of the muscles. | |
| void | updateKinematics (rigidbody::Joints &updatedModel, internal_forces::PathModifiers &pathModifiers, const rigidbody::GeneralizedCoordinates *Q=nullptr, const rigidbody::GeneralizedVelocity *Qdot=nullptr) |
| Updates the position and dynamic elements of the muscles. | |
| void | updateKinematics (std::vector< utils::Vector3d > &musclePointsInGlobal, utils::Matrix &jacoPointsInGlobal, const rigidbody::GeneralizedVelocity *Qdot=nullptr) |
| Updates the position and dynamic elements of the muscles by hand. | |
| void | setOrigin (const utils::Vector3d &position) |
| Set the origin position in the local reference frame of the muscle. | |
| const utils::Vector3d & | originInLocal () const |
| Return the origin position. | |
| void | setInsertionInLocal (const utils::Vector3d &position) |
| Set the insertion position. | |
| const utils::Vector3d & | insertionInLocal () const |
| Return the insertion position. | |
| const utils::Vector3d & | originInGlobal () const |
| Return the origin position in the global reference. | |
| const utils::Vector3d & | insertionInGlobal () const |
| Return the insertion position in the global reference. | |
| const std::vector< utils::Vector3d > & | pointsInGlobal () const |
| Return the muscles points in the global reference. | |
| const utils::Scalar & | length () const |
| Return the previously computed muscle length. | |
| const utils::Scalar & | velocity () const |
| Return the previously computed velocity. | |
| const utils::Matrix & | jacobian () const |
| Return the previously computed muscle jacobian. | |
| utils::Matrix | jacobianOrigin () const |
| Return the gradient of the jacobian for the origin node. | |
| utils::Matrix | jacobianInsertion () const |
| Return the gradient of the jacobian for the insertion node. | |
| utils::Matrix | jacobian (size_t idxViaPoint) const |
| Return the gradient of the jacobian for the via specified node. | |
| const utils::Matrix & | jacobianLength () const |
| Return the jacobian length of the muscle. | |
Protected Member Functions | |
| void | _updateKinematics (const rigidbody::GeneralizedVelocity *Qdot, const Characteristics *characteristics, internal_forces::PathModifiers *pathModifiers=nullptr) |
| Actual function that implements the update of the kinematics. | |
| const utils::Scalar & | length (const Characteristics *characteristics, internal_forces::PathModifiers *pathModifiers=nullptr) |
| Update the kinematics, compute and return the muscle length. | |
| Protected Member Functions inherited from BIORBD_NAMESPACE::internal_forces::Geometry | |
| void | _updateKinematics (const rigidbody::GeneralizedVelocity *Qdot, internal_forces::PathModifiers *pathModifiers=nullptr) |
| Actual function that implements the update of the kinematics. | |
| const utils::Vector3d & | originInGlobal (rigidbody::Joints &model, const rigidbody::GeneralizedCoordinates &Q) |
| Updates the kinematics and return the position of the origin node. | |
| const utils::Vector3d & | insertionInGlobal (rigidbody::Joints &model, const rigidbody::GeneralizedCoordinates &Q) |
| Updates the kinematics and return the position of the insertion node. | |
| void | setPointsInGlobal (std::vector< utils::Vector3d > &ptsInGlobal) |
| Set the muscle points in global. | |
| void | setPointsInGlobal (rigidbody::Joints &model, const rigidbody::GeneralizedCoordinates &Q, internal_forces::PathModifiers *pathModifiers=nullptr) |
| Set the muscle points in global. | |
| const utils::Scalar & | length (internal_forces::PathModifiers *pathModifiers=nullptr) |
| Update the kinematics, compute and return the muscle length. | |
| const utils::Scalar & | velocity (const rigidbody::GeneralizedVelocity &Qdot) |
| Update the kinematics, compute and return the muscle velocity assuming not via points nor wrapping objects. | |
| void | setJacobianDimension (rigidbody::Joints &model) |
| Set the jacobian dimensions. | |
| void | jacobian (const utils::Matrix &jaco) |
| Force a jacobian computed from the user. | |
| void | jacobian (rigidbody::Joints &model, const rigidbody::GeneralizedCoordinates &Q) |
| Compute the jacobian. | |
| void | computeJacobianLength () |
| Compute the muscle length jacobian. | |
Protected Attributes | |
| std::shared_ptr< utils::Scalar > | m_muscleLength |
| length | |
| std::shared_ptr< utils::Scalar > | m_muscleTendonLength |
| muscle tendon length | |
| Protected Attributes inherited from BIORBD_NAMESPACE::internal_forces::Geometry | |
| std::shared_ptr< utils::Vector3d > | m_origin |
| Origin node. | |
| std::shared_ptr< utils::Vector3d > | m_insertion |
| Insertion node. | |
| std::shared_ptr< utils::Vector3d > | m_originInGlobal |
| Position of the origin in the global reference. | |
| std::shared_ptr< utils::Vector3d > | m_insertionInGlobal |
| std::shared_ptr< std::vector< utils::Vector3d > > | m_pointsInGlobal |
| Position of all the points in the global reference. | |
| std::shared_ptr< std::vector< utils::Vector3d > > | m_pointsInLocal |
| Position of all the points in local. | |
| std::shared_ptr< utils::Matrix > | m_jacobian |
| The jacobian matrix. | |
| std::shared_ptr< utils::Matrix > | m_jacobianLength |
| The muscle length jacobian. | |
| std::shared_ptr< utils::Scalar > | m_length |
| length | |
| std::shared_ptr< utils::Scalar > | m_velocity |
| Velocity of the muscular elongation. | |
| std::shared_ptr< bool > | m_isGeometryComputed |
| std::shared_ptr< bool > | m_isVelocityComputed |
| std::shared_ptr< bool > | m_posAndJacoWereForced |
Detailed Description
Class muscle geometry of the muscle.
Definition at line 34 of file MuscleGeometry.h.
Constructor & Destructor Documentation
◆ MuscleGeometry() [1/2]
| internal_forces::muscles::MuscleGeometry::MuscleGeometry | ( | ) |
Construct muscle geometry.
Definition at line 24 of file MuscleGeometry.cpp.
◆ MuscleGeometry() [2/2]
| internal_forces::muscles::MuscleGeometry::MuscleGeometry | ( | const utils::Vector3d & | origin, |
| const utils::Vector3d & | insertion ) |
Construct muscle geometry.
- Parameters
-
origin The origin node of the muscle insertion The insertion node of the muscle
Definition at line 31 of file MuscleGeometry.cpp.
Member Function Documentation
◆ _updateKinematics()
|
protected |
Actual function that implements the update of the kinematics.
- Parameters
-
Qdot The generalized velocities characteristics The muscle characteristics pathModifiers The set of path modifiers
Definition at line 122 of file MuscleGeometry.cpp.
◆ DeepCopy() [1/2]
| internal_forces::muscles::MuscleGeometry internal_forces::muscles::MuscleGeometry::DeepCopy | ( | ) | const |
Deep copy of a muscle geometry.
- Returns
- A deep copy of a muscle geometry
Definition at line 39 of file MuscleGeometry.cpp.
◆ DeepCopy() [2/2]
| void internal_forces::muscles::MuscleGeometry::DeepCopy | ( | const MuscleGeometry & | other | ) |
Deep copy of a muscle geometry from another muscle geometry.
- Parameters
-
other The muscle geometry to copy
Definition at line 45 of file MuscleGeometry.cpp.
◆ length() [1/2]
| const utils::Scalar & internal_forces::muscles::MuscleGeometry::length | ( | ) | const |
Return the previously computed muscle length.
- Returns
- The muscle lengh
Definition at line 105 of file MuscleGeometry.cpp.
◆ length() [2/2]
|
protected |
Update the kinematics, compute and return the muscle length.
- Parameters
-
characteristics The muscle characteristics pathModifiers The set of path modifiers
- Returns
- The muscle length
Definition at line 140 of file MuscleGeometry.cpp.
◆ musculoTendonLength()
| const utils::Scalar & internal_forces::muscles::MuscleGeometry::musculoTendonLength | ( | ) | const |
Return the previously computed muscle tendon length.
- Returns
- The muscle tendon lengh
Definition at line 113 of file MuscleGeometry.cpp.
◆ updateKinematics() [1/3]
| void internal_forces::muscles::MuscleGeometry::updateKinematics | ( | rigidbody::Joints & | updatedModel, |
| const Characteristics & | characteristics, | ||
| const rigidbody::GeneralizedCoordinates * | Q = nullptr, | ||
| const rigidbody::GeneralizedVelocity * | Qdot = nullptr ) |
Updates the position and dynamic elements of the muscles.
- Parameters
-
updatedModel The joint model previously updated to the proper level characteristics The muscle characteristics Q The generalized coordinates of the joints (not needed if updateKinLevel is less than 2) Qdot The generalized velocities of the joints (not needed if updateKinLevel is less than 2)
updateKinematics MUST be called before retreiving data that are dependent on Q and/or Qdot
WARNING, using updateKinematics overrides the previously sent position and jacobian
Definition at line 53 of file MuscleGeometry.cpp.
◆ updateKinematics() [2/3]
| void internal_forces::muscles::MuscleGeometry::updateKinematics | ( | rigidbody::Joints & | updatedModel, |
| const Characteristics & | characteristics, | ||
| internal_forces::PathModifiers & | pathModifiers, | ||
| const rigidbody::GeneralizedCoordinates * | Q = nullptr, | ||
| const rigidbody::GeneralizedVelocity * | Qdot = nullptr ) |
Updates the position and dynamic elements of the muscles.
- Parameters
-
updatedModel The joint model previously updated to the proper level characteristics The muscle characteristics pathModifiers The path modifiers Q The generalized coordinates of the joints (not needed if updateKinLevel is less than 2) Qdot The generalized velocities of the joints (not needed if updateKinLevel is less than 2)
updateKinematics MUST be called before retreiving data that are dependent on Q and/or Qdot
WARNING, using updateKinematics overrides the previously sent position and jacobian
Definition at line 70 of file MuscleGeometry.cpp.
◆ updateKinematics() [3/3]
| void internal_forces::muscles::MuscleGeometry::updateKinematics | ( | std::vector< utils::Vector3d > & | musclePointsInGlobal, |
| utils::Matrix & | jacoPointsInGlobal, | ||
| const Characteristics & | characteristics, | ||
| const rigidbody::GeneralizedVelocity * | Qdot = nullptr ) |
Updates the position and dynamic elements of the muscles by hand.
- Parameters
-
musclePointsInGlobal Position of all the points in global jacoPointsInGlobal Position of all the Jacobian points in global characteristics The muscle characteristics Qdot The generalized velocities of the joints
updateKinematics MUST be called before retreiving data that are dependent on Q and/or Qdot
Definition at line 88 of file MuscleGeometry.cpp.
Member Data Documentation
◆ m_muscleLength
|
protected |
length
Definition at line 157 of file MuscleGeometry.h.
◆ m_muscleTendonLength
|
protected |
muscle tendon length
Definition at line 159 of file MuscleGeometry.h.
The documentation for this class was generated from the following files:
