Loading...
Searching...
No Matches
BIORBD_NAMESPACE::internal_forces::muscles::StaticOptimizationIpopt Class Reference
The actual implementation of the Static Optimization problem. More...
#include <StaticOptimizationIpopt.h>
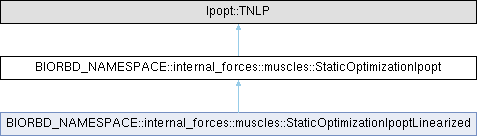
Inheritance diagram for BIORBD_NAMESPACE::internal_forces::muscles::StaticOptimizationIpopt:
Public Member Functions | |
| StaticOptimizationIpopt (Model &model, const rigidbody::GeneralizedCoordinates &Q, const rigidbody::GeneralizedVelocity &Qdot, const rigidbody::GeneralizedTorque &torqueTarget, const utils::Vector &activationInit, bool useResidual=true, unsigned int pNormFactor=2, int verbose=0, double eps=1e-8) | |
| Construct an Ipopt static optimization problem. | |
| virtual | ~StaticOptimizationIpopt () |
| Destroy class properly. | |
| virtual bool | get_nlp_info (Ipopt::Index &n, Ipopt::Index &m, Ipopt::Index &nnz_jac_g, Ipopt::Index &nnz_h_lag, IndexStyleEnum &index_style) |
| Get info about the NLP. | |
| virtual bool | get_bounds_info (Ipopt::Index n, Ipopt::Number *x_l, Ipopt::Number *x_u, Ipopt::Index m, Ipopt::Number *g_l, Ipopt::Number *g_u) |
| Return the bounds for my problem. | |
| virtual bool | get_starting_point (Ipopt::Index n, bool init_x, Ipopt::Number *x, bool init_z, Ipopt::Number *z_L, Ipopt::Number *z_U, Ipopt::Index m, bool init_lambda, Ipopt::Number *lambda) |
| Return the starting point for the algorithm. | |
| virtual bool | eval_f (Ipopt::Index n, const Ipopt::Number *x, bool new_x, Ipopt::Number &obj_value) |
| Compute the objective value from a set of variables. | |
| virtual bool | eval_grad_f (Ipopt::Index n, const Ipopt::Number *x, bool new_x, Ipopt::Number *grad_f) |
| Return the gradient of the objective. | |
| virtual bool | eval_g (Ipopt::Index n, const Ipopt::Number *x, bool new_x, Ipopt::Index m, Ipopt::Number *g) |
| Method to return the constraint residuals. | |
| virtual bool | eval_jac_g (Ipopt::Index n, const Ipopt::Number *x, bool new_x, Ipopt::Index m, Ipopt::Index nele_jac, Ipopt::Index *iRow, Ipopt::Index *jCol, Ipopt::Number *values) |
| Return the jacobian of contraints. | |
| virtual void | finalize_solution (Ipopt::SolverReturn status, Ipopt::Index n, const Ipopt::Number *x, const Ipopt::Number *z_L, const Ipopt::Number *z_U, Ipopt::Index m, const Ipopt::Number *g, const Ipopt::Number *lambda, Ipopt::Number obj_value, const Ipopt::IpoptData *ip_data, Ipopt::IpoptCalculatedQuantities *ip_cq) |
| Finalize the optimization. | |
| utils::Vector | finalSolution () const |
| Return the final solution. | |
| utils::Vector | finalResidual () const |
| Return the final residual. | |
Protected Member Functions | |
| void | dispatch (const Ipopt::Number *x) |
| To dispatch the variables into biorbd format. | |
Protected Attributes | |
| Model & | m_model |
| The model. | |
| std::shared_ptr< unsigned int > | m_nbQ |
| The number of generalized coordinates. | |
| std::shared_ptr< unsigned int > | m_nbQdot |
| The number of generalized velocities. | |
| std::shared_ptr< unsigned int > | m_nbMus |
| The number of muscles. | |
| std::shared_ptr< unsigned int > | m_nbDof |
| The number of degrees of freedom. | |
| std::shared_ptr< unsigned int > | m_nbTorque |
| The number of torques to match. | |
| std::shared_ptr< unsigned int > | m_nbTorqueResidual |
| The number of torque residual. | |
| std::shared_ptr< double > | m_eps |
| Precision of the finite differentiate. | |
| std::shared_ptr< utils::Vector > | m_activations |
| The activations. | |
| std::shared_ptr< rigidbody::GeneralizedCoordinates > | m_Q |
| The generalized coordinates. | |
| std::shared_ptr< rigidbody::GeneralizedVelocity > | m_Qdot |
| The generalized velocities. | |
| std::shared_ptr< rigidbody::GeneralizedTorque > | m_torqueTarget |
| The torque to match. | |
| std::shared_ptr< utils::Vector > | m_torqueResidual |
| The torque residual. | |
| std::shared_ptr< double > | m_torquePonderation |
| The torque ponderation. | |
| std::shared_ptr< std::vector< std::shared_ptr< State > > > | m_states |
| The muscle states. | |
| std::shared_ptr< unsigned int > | m_pNormFactor |
| The p-norm factor. | |
| std::shared_ptr< int > | m_verbose |
| Verbose level of IPOPT. | |
| std::shared_ptr< utils::Vector > | m_finalSolution |
| The final solution. | |
| std::shared_ptr< utils::Vector > | m_finalResidual |
| The final residual. | |
Static Protected Attributes | |
| static const double | m_activationLowerBound = 0.0001 |
| Minimal muscle activation. | |
| static const double | m_activationUpperBound = 0.9999 |
| Maximal muscle activation. | |
Detailed Description
The actual implementation of the Static Optimization problem.
Definition at line 29 of file StaticOptimizationIpopt.h.
Constructor & Destructor Documentation
◆ StaticOptimizationIpopt()
| internal_forces::muscles::StaticOptimizationIpopt::StaticOptimizationIpopt | ( | Model & | model, |
| const rigidbody::GeneralizedCoordinates & | Q, | ||
| const rigidbody::GeneralizedVelocity & | Qdot, | ||
| const rigidbody::GeneralizedTorque & | torqueTarget, | ||
| const utils::Vector & | activationInit, | ||
| bool | useResidual = true, | ||
| unsigned int | pNormFactor = 2, | ||
| int | verbose = 0, | ||
| double | eps = 1e-8 ) |
Construct an Ipopt static optimization problem.
- Parameters
-
model The musculoskeletal Model Q The generalized coordinates Qdot The generalized velocities torqueTarget The generalized torque target activationInit The initial activation useResidual If use residual torque, if set to false, the optimization will fail if the model is not strong enough pNormFactor The p-norm to perform verbose Level of IPOPT verbose you want eps The precision to perform the finite diffentiation
Definition at line 24 of file StaticOptimizationIpopt.cpp.
◆ ~StaticOptimizationIpopt()
|
virtual |
Destroy class properly.
Definition at line 79 of file StaticOptimizationIpopt.cpp.
Member Function Documentation
◆ dispatch()
|
protected |
To dispatch the variables into biorbd format.
- Parameters
-
x variables
Definition at line 372 of file StaticOptimizationIpopt.cpp.
◆ eval_f()
|
virtual |
Compute the objective value from a set of variables.
- Parameters
-
n The number of variables x The values of the variables new_x If the variables were modified by IPOPT obj_value The actual value of the objective function
- Returns
- Return the presence of that function
Definition at line 171 of file StaticOptimizationIpopt.cpp.
◆ eval_g()
|
virtual |
Method to return the constraint residuals.
- Parameters
-
n The number of variables x The values of the variables new_x If the variables were modified by IPOPT m The number of constraints g The actual contraints residual
- Returns
- Return the presence of that function
Reimplemented in BIORBD_NAMESPACE::internal_forces::muscles::StaticOptimizationIpoptLinearized.
Definition at line 213 of file StaticOptimizationIpopt.cpp.
◆ eval_grad_f()
|
virtual |
Return the gradient of the objective.
- Parameters
-
n The number of variables x The values of the variables new_x If the variables were modified by IPOPT grad_f The gradient vector of the objective function
- Returns
- Return the presence of that function
Definition at line 190 of file StaticOptimizationIpopt.cpp.
◆ eval_jac_g()
|
virtual |
Return the jacobian of contraints.
- Parameters
-
n The number of variables x The values of the variables new_x If the variables were modified by IPOPT m The number of constraints nele_jac Number of elements in the jacobian matrix iRow iterator on the rows of the jacobian jCol iterator on the columns of the jacobian values The actual constraint jacobian
- Returns
- Return the presence of that function
Reimplemented in BIORBD_NAMESPACE::internal_forces::muscles::StaticOptimizationIpoptLinearized.
Definition at line 242 of file StaticOptimizationIpopt.cpp.
◆ finalize_solution()
|
virtual |
Finalize the optimization.
- Parameters
-
status The status of the optimization n Number of variables x Optimal solution z_L Optimal lower bound of z (ignored result) z_U Optimal upper bound of z (ignored result) m number of constraints g Residual at solution lambda Lagrange multipliers at solution obj_value Objective function value at solution ip_data Not used results ip_cq Not used results
Definition at line 323 of file StaticOptimizationIpopt.cpp.
◆ finalResidual()
| utils::Vector internal_forces::muscles::StaticOptimizationIpopt::finalResidual | ( | ) | const |
Return the final residual.
- Returns
- The final residual (zeros if finalize_solution was not called, e.g. if IPOPT aborted)
Definition at line 367 of file StaticOptimizationIpopt.cpp.
◆ finalSolution()
| utils::Vector internal_forces::muscles::StaticOptimizationIpopt::finalSolution | ( | ) | const |
Return the final solution.
- Returns
- The final solution (the initial activations if finalize_solution was not called, e.g. if IPOPT aborted)
Definition at line 362 of file StaticOptimizationIpopt.cpp.
◆ get_bounds_info()
|
virtual |
Return the bounds for my problem.
- Parameters
-
n Number of variables x_l Lower bounds of the variables x_u Upper bounds of the variables m Number of constraints g_l Lower bounds of the constraints g_u Upper bounds of the constraints
- Returns
- Return the presence of that function
Definition at line 109 of file StaticOptimizationIpopt.cpp.
◆ get_nlp_info()
|
virtual |
Get info about the NLP.
- Parameters
-
n Number of variables m Number of constraints nnz_jac_g Dimension of the constraint jacobian nnz_h_lag Dimension of the constraint hessian index_style Formatting of the matrix (C-Style)
- Returns
- Return the presence of that function
Definition at line 81 of file StaticOptimizationIpopt.cpp.
◆ get_starting_point()
|
virtual |
Return the starting point for the algorithm.
- Parameters
-
n Number of variables init_x If variables are initialized. That variable must be true x The initial values for the variables (output) init_z If z parameters are initialized. That variable must be false z_L Lower bound of z (ignored output) z_U Upper bound of z (ignored output) m Number of constraints init_lambda If lambda parameters are initialized. That variable must be false lambda Initial values of lagrange multipliers (ignored output)
- Returns
- Return the presence of that function
Definition at line 138 of file StaticOptimizationIpopt.cpp.
Member Data Documentation
◆ m_activationLowerBound
|
staticprotected |
Minimal muscle activation.
Definition at line 228 of file StaticOptimizationIpopt.h.
◆ m_activations
|
protected |
The activations.
Definition at line 242 of file StaticOptimizationIpopt.h.
◆ m_activationUpperBound
|
staticprotected |
Maximal muscle activation.
Definition at line 229 of file StaticOptimizationIpopt.h.
◆ m_eps
|
protected |
Precision of the finite differentiate.
Definition at line 241 of file StaticOptimizationIpopt.h.
◆ m_finalResidual
|
protected |
The final residual.
Definition at line 256 of file StaticOptimizationIpopt.h.
◆ m_finalSolution
|
protected |
The final solution.
Definition at line 255 of file StaticOptimizationIpopt.h.
◆ m_model
|
protected |
The model.
Definition at line 231 of file StaticOptimizationIpopt.h.
◆ m_nbDof
|
protected |
The number of degrees of freedom.
Definition at line 237 of file StaticOptimizationIpopt.h.
◆ m_nbMus
|
protected |
The number of muscles.
Definition at line 236 of file StaticOptimizationIpopt.h.
◆ m_nbQ
|
protected |
The number of generalized coordinates.
Definition at line 233 of file StaticOptimizationIpopt.h.
◆ m_nbQdot
|
protected |
The number of generalized velocities.
Definition at line 235 of file StaticOptimizationIpopt.h.
◆ m_nbTorque
|
protected |
The number of torques to match.
Definition at line 238 of file StaticOptimizationIpopt.h.
◆ m_nbTorqueResidual
|
protected |
The number of torque residual.
Definition at line 240 of file StaticOptimizationIpopt.h.
◆ m_pNormFactor
|
protected |
The p-norm factor.
Definition at line 253 of file StaticOptimizationIpopt.h.
◆ m_Q
|
protected |
The generalized coordinates.
Definition at line 244 of file StaticOptimizationIpopt.h.
◆ m_Qdot
|
protected |
The generalized velocities.
Definition at line 246 of file StaticOptimizationIpopt.h.
◆ m_states
|
protected |
The muscle states.
Definition at line 252 of file StaticOptimizationIpopt.h.
◆ m_torquePonderation
|
protected |
The torque ponderation.
Definition at line 250 of file StaticOptimizationIpopt.h.
◆ m_torqueResidual
|
protected |
The torque residual.
Definition at line 249 of file StaticOptimizationIpopt.h.
◆ m_torqueTarget
|
protected |
The torque to match.
Definition at line 248 of file StaticOptimizationIpopt.h.
◆ m_verbose
|
protected |
Verbose level of IPOPT.
Definition at line 254 of file StaticOptimizationIpopt.h.
The documentation for this class was generated from the following files:
