Loading...
Searching...
No Matches
BIORBD_NAMESPACE::rigidbody::GeneralizedAcceleration Class Reference
Class GeneralizedAcceleration. More...
#include <GeneralizedAcceleration.h>
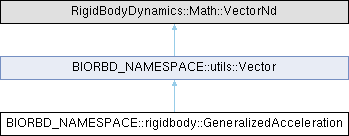
Inheritance diagram for BIORBD_NAMESPACE::rigidbody::GeneralizedAcceleration:
Public Member Functions | |
| GeneralizedAcceleration () | |
| Construct generalized acceleration vector. | |
| GeneralizedAcceleration (size_t nQddot) | |
| Create generalized acceleration vector of dimension nQddot. | |
| GeneralizedAcceleration (const rigidbody::Joints &j) | |
| Create generalized acceleration vector from a joint Model. | |
| GeneralizedAcceleration (const GeneralizedAcceleration &Q) | |
| Construct generalized acceleration vector. | |
| GeneralizedAcceleration (const RigidBodyDynamics::Math::VectorNd &v) | |
| Construct vector from Casadi vector. | |
| virtual | ~GeneralizedAcceleration () |
| Destroy the class properly. | |
| void | operator= (const utils::Vector &other) |
| operator= For submatrices | |
| Public Member Functions inherited from BIORBD_NAMESPACE::utils::Vector | |
| Vector () | |
| Construct vector. | |
| Vector (size_t size) | |
| Construct vector of dimension size. | |
| Vector (const Vector &other) | |
| Construct vector from Casadi vector. | |
| Vector (const RigidBodyDynamics::Math::VectorNd &other) | |
| Construct vector from Casadi vector. | |
| Vector (const Vector3d &other) | |
| Construct vector from Casadi matrix. | |
| Scalar | norm (size_t p=2, bool skipRoot=false) const |
| Return the Euclidian p-norm of the vector. | |
| Vector | normGradient (size_t p=2, bool skipRoot=false) |
| Return the gradient of the p-norm. | |
| void | operator= (const Vector &other) |
| operator= For submatrices | |
Detailed Description
Class GeneralizedAcceleration.
Definition at line 15 of file GeneralizedAcceleration.h.
Constructor & Destructor Documentation
◆ GeneralizedAcceleration() [1/5]
| rigidbody::GeneralizedAcceleration::GeneralizedAcceleration | ( | ) |
Construct generalized acceleration vector.
Definition at line 8 of file GeneralizedAcceleration.cpp.
◆ GeneralizedAcceleration() [2/5]
| rigidbody::GeneralizedAcceleration::GeneralizedAcceleration | ( | size_t | nQddot | ) |
Create generalized acceleration vector of dimension nQddot.
- Parameters
-
nQddot number of degrees-of-freedom
Definition at line 10 of file GeneralizedAcceleration.cpp.
◆ GeneralizedAcceleration() [3/5]
| rigidbody::GeneralizedAcceleration::GeneralizedAcceleration | ( | const rigidbody::Joints & | j | ) |
Create generalized acceleration vector from a joint Model.
- Parameters
-
j The joint model
Definition at line 13 of file GeneralizedAcceleration.cpp.
◆ GeneralizedAcceleration() [4/5]
| rigidbody::GeneralizedAcceleration::GeneralizedAcceleration | ( | const GeneralizedAcceleration & | Q | ) |
Construct generalized acceleration vector.
- Parameters
-
Q State vector of the internal joints
Definition at line 17 of file GeneralizedAcceleration.cpp.
◆ GeneralizedAcceleration() [5/5]
| rigidbody::GeneralizedAcceleration::GeneralizedAcceleration | ( | const RigidBodyDynamics::Math::VectorNd & | v | ) |
Construct vector from Casadi vector.
- Parameters
-
v The vector to copy
Definition at line 21 of file GeneralizedAcceleration.cpp.
◆ ~GeneralizedAcceleration()
|
virtual |
Destroy the class properly.
Definition at line 32 of file GeneralizedAcceleration.cpp.
Member Function Documentation
◆ operator=()
| void rigidbody::GeneralizedAcceleration::operator= | ( | const utils::Vector & | other | ) |
operator= For submatrices
- Parameters
-
other The vector to copy
Definition at line 34 of file GeneralizedAcceleration.cpp.
The documentation for this class was generated from the following files:
