Loading...
Searching...
No Matches
BIORBD_NAMESPACE::utils::RotoTrans Class Reference
Homogenous matrix to describe translations and rotations simultaneously. More...
#include <RotoTrans.h>
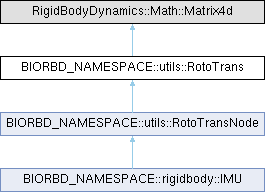
Inheritance diagram for BIORBD_NAMESPACE::utils::RotoTrans:
Public Member Functions | |
| RotoTrans (const RigidBodyDynamics::Math::Matrix4d &matrix=RigidBodyDynamics::Math::Matrix4d::Identity()) | |
| Construct RotoTrans matrix. | |
| RotoTrans (const Scalar &v00, const Scalar &v01, const Scalar &v02, const Scalar &v03, const Scalar &v10, const Scalar &v11, const Scalar &v12, const Scalar &v13, const Scalar &v20, const Scalar &v21, const Scalar &v22, const Scalar &v23, const Scalar &v30, const Scalar &v31, const Scalar &v32, const Scalar &v33) | |
| RotoTrans Construct a RotoTrans matrix by elements. | |
| RotoTrans (const Rotation &rot) | |
| Contruct Rototrans. | |
| RotoTrans (const Rotation &rot, const Vector3d &trans) | |
| Contruct Rototrans. | |
| RotoTrans (const Vector &rotation, const Vector3d &translation, const String &rotationSequence) | |
| Contruct Rototrans. | |
| RotoTrans (const utils::SpatialTransform &st) | |
| Contruct Rototrans. | |
| Vector3d | axe (size_t idx) const |
| Get a particular axis of the rotation matrix. | |
| RotoTrans | transpose () const |
| Return the tranposed matrix. | |
| Vector3d | trans () const |
| Return the translation vector. | |
| Rotation | rot () const |
| Return the rotation matrix. | |
| void | checkUnitary () |
| Check if the RotoTrans has a unitary matrix of rotation and the last row is (0, 0, 0, 1). | |
Static Public Member Functions | |
| static RotoTrans | fromMarkers (const rigidbody::NodeSegment &origin, const std::pair< rigidbody::NodeSegment, rigidbody::NodeSegment > &axis1markers, const std::pair< rigidbody::NodeSegment, rigidbody::NodeSegment > &axis2markers, const std::pair< String, String > &axesNames, const String &axisToRecalculate) |
| fromMarkers Creates a system of axes from two axes and an origin defined by markers | |
| static RotoTrans | combineRotAndTrans (const Rotation &rot, const Vector3d &trans) |
| Set the RotoTrans from a rotation and a translation. | |
| static RotoTrans | fromSpatialTransform (const utils::SpatialTransform &st) |
| set the RotoTrans from a spatial transform | |
| static RotoTrans | fromEulerAngles (const Vector &rot, const Vector3d &trans, const String &seq) |
| Create a RotoTrans from Euler angles. | |
| static Vector | toEulerAngles (const RotoTrans &rt, const String &seq) |
| Return extracted angles from the rotation matrix into Euler angles using the provided sequence. | |
| static utils::RotoTrans | mean (const std::vector< utils::RotoTrans > &rt) |
| Get the mean of the 4x4 matrices. | |
Protected Member Functions | |
| RigidBodyDynamics::Math::Vector4d | expand3dTo4d (const Vector3d &v1) |
| Expand 3D vector to 4D (padding with an extra 1). | |
Detailed Description
Homogenous matrix to describe translations and rotations simultaneously.
Definition at line 31 of file RotoTrans.h.
Constructor & Destructor Documentation
◆ RotoTrans() [1/6]
| utils::RotoTrans::RotoTrans | ( | const RigidBodyDynamics::Math::Matrix4d & | matrix = RigidBodyDynamics::Math::Matrix4d::Identity() | ) |
Construct RotoTrans matrix.
- Parameters
-
matrix 4D identity matrix
Definition at line 14 of file RotoTrans.cpp.
◆ RotoTrans() [2/6]
| utils::RotoTrans::RotoTrans | ( | const Scalar & | v00, |
| const Scalar & | v01, | ||
| const Scalar & | v02, | ||
| const Scalar & | v03, | ||
| const Scalar & | v10, | ||
| const Scalar & | v11, | ||
| const Scalar & | v12, | ||
| const Scalar & | v13, | ||
| const Scalar & | v20, | ||
| const Scalar & | v21, | ||
| const Scalar & | v22, | ||
| const Scalar & | v23, | ||
| const Scalar & | v30, | ||
| const Scalar & | v31, | ||
| const Scalar & | v32, | ||
| const Scalar & | v33 ) |
RotoTrans Construct a RotoTrans matrix by elements.
- Parameters
-
v00 Row 0, Col 0 v01 Row 0, Col 1 v02 Row 0, Col 2 v03 Row 0, Col 3 v10 Row 1, Col 0 v11 Row 1, Col 1 v12 Row 1, Col 2 v13 Row 1, Col 3 v20 Row 2, Col 0 v21 Row 2, Col 1 v22 Row 2, Col 2 v23 Row 2, Col 3 v30 Row 3, Col 0 v31 Row 3, Col 1 v32 Row 3, Col 2 v33 Row 3, Col 3
Definition at line 19 of file RotoTrans.cpp.
◆ RotoTrans() [3/6]
| utils::RotoTrans::RotoTrans | ( | const Rotation & | rot | ) |
◆ RotoTrans() [4/6]
Contruct Rototrans.
- Parameters
-
rot The rotation matrix trans Translation vector
Definition at line 60 of file RotoTrans.cpp.
◆ RotoTrans() [5/6]
| utils::RotoTrans::RotoTrans | ( | const Vector & | rotation, |
| const Vector3d & | translation, | ||
| const String & | rotationSequence ) |
Contruct Rototrans.
- Parameters
-
rotation The Euler angles vector translation The translation vector rotationSequence The rotation sequence
The number of rotation must match the number of axes in the rotation sequence
Definition at line 65 of file RotoTrans.cpp.
◆ RotoTrans() [6/6]
| utils::RotoTrans::RotoTrans | ( | const utils::SpatialTransform & | st | ) |
Contruct Rototrans.
- Parameters
-
st Spatial Transform vector
Definition at line 72 of file RotoTrans.cpp.
Member Function Documentation
◆ axe()
| utils::Vector3d utils::RotoTrans::axe | ( | size_t | idx | ) | const |
Get a particular axis of the rotation matrix.
- Parameters
-
idx The index of axis (x = 0, y = 1 and z = 2)
- Returns
- The axis
Definition at line 90 of file RotoTrans.cpp.
◆ checkUnitary()
| void utils::RotoTrans::checkUnitary | ( | ) |
Check if the RotoTrans has a unitary matrix of rotation and the last row is (0, 0, 0, 1).
That function throws a runtime_error if the check fails
Definition at line 174 of file RotoTrans.cpp.
◆ combineRotAndTrans()
|
static |
Set the RotoTrans from a rotation and a translation.
- Parameters
-
rot The matrix of rotation trans The vector of translation
- Returns
- The matrix of RotoTrans
Definition at line 112 of file RotoTrans.cpp.
◆ expand3dTo4d()
|
protected |
Expand 3D vector to 4D (padding with an extra 1).
- Parameters
-
v1 Vector to expand
- Returns
- The expanded 4D vector
Definition at line 166 of file RotoTrans.cpp.
◆ fromEulerAngles()
|
static |
Create a RotoTrans from Euler angles.
- Parameters
-
rot The Euler angles vector trans The translation vector seq The rotation sequence
- Returns
- The RotoTrans matrix
The number of rotation umust match the number of axes in the rotation sequence
Definition at line 128 of file RotoTrans.cpp.
◆ fromMarkers()
|
static |
fromMarkers Creates a system of axes from two axes and an origin defined by markers
- Parameters
-
origin The position of the origin axis1markers The beginning and ending of the vector of the first axis axis2markers The beginning and ending of the vector of the second axis axesNames The names ("x", "y" or "z") of the axes axisToRecalculate The axis to recalculate to ensure orthonormal system of axes
- Returns
- The system of axes
Definition at line 75 of file RotoTrans.cpp.
◆ fromSpatialTransform()
|
static |
set the RotoTrans from a spatial transform
- Parameters
-
st The spatial transform
- Returns
- The matrix of RotoTrans
Definition at line 123 of file RotoTrans.cpp.
◆ mean()
|
static |
Get the mean of the 4x4 matrices.
- Parameters
-
rt The RotoTrans matrices to mean
- Returns
- The mean RotoTrans
Definition at line 147 of file RotoTrans.cpp.
◆ rot()
| utils::Rotation utils::RotoTrans::rot | ( | ) | const |
Return the rotation matrix.
- Returns
- The rotation matrix
Definition at line 108 of file RotoTrans.cpp.
◆ toEulerAngles()
|
static |
Return extracted angles from the rotation matrix into Euler angles using the provided sequence.
- Parameters
-
rt The RotoTrans matrix to extract angles from seq The angle sequence
- Returns
- The angles (the length of the vector will match the length of sequence)
The rotation sequence can be any combination of x, y and z
Definition at line 140 of file RotoTrans.cpp.
◆ trans()
| utils::Vector3d utils::RotoTrans::trans | ( | ) | const |
Return the translation vector.
- Returns
- The translation vector
Definition at line 104 of file RotoTrans.cpp.
◆ transpose()
| utils::RotoTrans utils::RotoTrans::transpose | ( | ) | const |
Return the tranposed matrix.
- Returns
- The transposed matrix
Definition at line 95 of file RotoTrans.cpp.
The documentation for this class was generated from the following files:
