Loading...
Searching...
No Matches
BIORBD_NAMESPACE::internal_forces::WrappingObject Class Referenceabstract
Base class for the wrapping objects. More...
#include <WrappingObject.h>
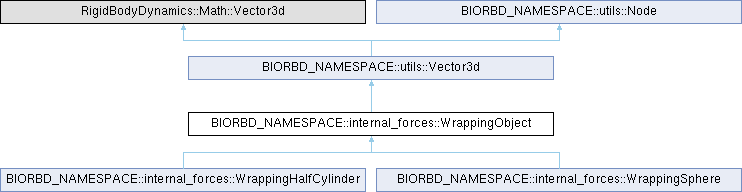
Inheritance diagram for BIORBD_NAMESPACE::internal_forces::WrappingObject:
Public Member Functions | |
| WrappingObject () | |
| Construct a wrapping object. | |
| WrappingObject (const utils::Scalar &x, const utils::Scalar &y, const utils::Scalar &z) | |
| Construct a wrapping object. | |
| WrappingObject (const utils::Scalar &x, const utils::Scalar &y, const utils::Scalar &z, const utils::String &name, const utils::String &parentName) | |
| Construct a wrapping object. | |
| WrappingObject (const utils::Vector3d &other) | |
| Construct a wrapping object. | |
| WrappingObject (const utils::Vector3d &other, const utils::String &name, const utils::String &parentName) | |
| Construct a wrapping object. | |
| void | DeepCopy (const WrappingObject &other) |
| Deep copy of the wrapping ibject in another wrapping object. | |
| virtual void | wrapPoints (const utils::RotoTrans &rt, const utils::Vector3d &p1_bone, const utils::Vector3d &p2_bone, utils::Vector3d &p1, utils::Vector3d &p2, utils::Scalar *muscleLength=nullptr)=0 |
| From the position of the wrapping object, return the 2 locations where the muscle leaves the wrapping object. | |
| virtual void | wrapPoints (rigidbody::Joints &model, const rigidbody::GeneralizedCoordinates &Q, const utils::Vector3d &p1_bone, const utils::Vector3d &p2_bone, utils::Vector3d &p1, utils::Vector3d &p2, utils::Scalar *muscleLength=nullptr)=0 |
| From the position of the wrapping object, return the 2 locations where the muscle leaves the wrapping object. | |
| virtual void | wrapPoints (utils::Vector3d &p1, utils::Vector3d &p2, utils::Scalar *muscleLength=nullptr)=0 |
| Returns the previously computed 2 locations where the muscle leaves the wrapping object. | |
| virtual const utils::RotoTrans & | RT (rigidbody::Joints &model, const rigidbody::GeneralizedCoordinates &Q, bool updateKin=true)=0 |
| Return the RotoTrans matrix of the wrapping object. | |
| const utils::RotoTrans & | RT () const |
| Return the RotoTrans matrix of the wrapping object. | |
| WrappingObject & | operator= (const utils::Vector3d &other) |
| To be able to use the equal "=" operator to define wrapping object. | |
| Public Member Functions inherited from BIORBD_NAMESPACE::utils::Vector3d | |
| Vector3d () | |
| Construct 3D vector. | |
| Vector3d (const Scalar &x, const Scalar &y, const Scalar &z) | |
| Construct 3D vector. | |
| Vector3d (const Scalar &x, const Scalar &y, const Scalar &z, const String &name, const String &parentName) | |
| Construct a 3D vector. | |
| Vector3d (const Vector3d vec, const String &name, const String &parentName) | |
| Construct a 3D vector. | |
| Vector3d (const RigidBodyDynamics::Math::Vector3d &other) | |
| Construct a 3D vector from a Casadi 3D vector (drop the trailling 1). | |
| Vector3d (const RigidBodyDynamics::Math::VectorNd &other) | |
| Construct a 3D vector from a Casadi ND vector (drop the trailling 1). | |
| Vector3d (const RigidBodyDynamics::Math::Vector4d &other) | |
| Construct a 3D vector from an eigen 4D vector (drop the trailling 1). | |
| Vector3d | DeepCopy () const |
| Deep copy of a 3D vector. | |
| void | DeepCopy (const Vector3d &other) |
| Deep copy of a 3D vector into another 3D vector. | |
| Vector3d | applyRT (const RotoTrans &rt) const |
| Apply a RotoTrans to the 3D vector. | |
| void | applyRT (const RotoTrans &rt) |
| Apply a RotoTrans to the 3D vector. | |
| void | setPosition (const Vector3d &v) |
| Set a new position. | |
| Public Member Functions inherited from BIORBD_NAMESPACE::utils::Node | |
| Node () | |
| Construct Node. | |
| Node (const Node &other) | |
| Construct Node from another node. | |
| Node (const String &name) | |
| Construct Node. | |
| Node (const String &name, const String &parentName) | |
| Construct Node. | |
| virtual | ~Node () |
| Destroy class properly. | |
| void | DeepCopy (const Node &other) |
| Deep copy of the node in another node. | |
| void | setName (const String &name) |
| Set the name of the node. | |
| const String & | name () const |
| Return the name of the node. | |
| const String & | parent () const |
| Return the parent name of the node. | |
| void | setParent (const String &name) |
| Set the parent name of the node. | |
| NODE_TYPE | typeOfNode () const |
| Return the type of node. | |
Protected Attributes | |
| std::shared_ptr< utils::RotoTrans > | m_RT |
| RotoTrans matrix of the wrapping object. | |
| Protected Attributes inherited from BIORBD_NAMESPACE::utils::Node | |
| std::shared_ptr< String > | m_name |
| The name of the node. | |
| std::shared_ptr< String > | m_parentName |
| The parent name of the node. | |
| std::shared_ptr< NODE_TYPE > | m_typeOfNode |
| The type of the node. | |
Additional Inherited Members | |
| Protected Member Functions inherited from BIORBD_NAMESPACE::utils::Vector3d | |
| void | setType () |
| Set the type Vector3d. | |
Detailed Description
Base class for the wrapping objects.
Definition at line 23 of file WrappingObject.h.
Constructor & Destructor Documentation
◆ WrappingObject() [1/5]
| internal_forces::WrappingObject::WrappingObject | ( | ) |
Construct a wrapping object.
Definition at line 9 of file WrappingObject.cpp.
◆ WrappingObject() [2/5]
| internal_forces::WrappingObject::WrappingObject | ( | const utils::Scalar & | x, |
| const utils::Scalar & | y, | ||
| const utils::Scalar & | z ) |
Construct a wrapping object.
- Parameters
-
x X-Component of the wrapping object y Y-Component of the wrapping object z Z-Component of the wrapping object
Definition at line 14 of file WrappingObject.cpp.
◆ WrappingObject() [3/5]
| internal_forces::WrappingObject::WrappingObject | ( | const utils::Scalar & | x, |
| const utils::Scalar & | y, | ||
| const utils::Scalar & | z, | ||
| const utils::String & | name, | ||
| const utils::String & | parentName ) |
Construct a wrapping object.
- Parameters
-
x X-Component of the wrapping object y Y-Component of the wrapping object z Z-Component of the wrapping object name Name of the wrapping object parentName Name of the parent segment
Definition at line 22 of file WrappingObject.cpp.
◆ WrappingObject() [4/5]
| internal_forces::WrappingObject::WrappingObject | ( | const utils::Vector3d & | other | ) |
Construct a wrapping object.
- Parameters
-
other Eigen vector
Definition at line 33 of file WrappingObject.cpp.
◆ WrappingObject() [5/5]
| internal_forces::WrappingObject::WrappingObject | ( | const utils::Vector3d & | other, |
| const utils::String & | name, | ||
| const utils::String & | parentName ) |
Construct a wrapping object.
- Parameters
-
other Eigen vector name Name of the wrapping object parentName Name of the parent segment
Definition at line 45 of file WrappingObject.cpp.
Member Function Documentation
◆ DeepCopy()
| void internal_forces::WrappingObject::DeepCopy | ( | const WrappingObject & | other | ) |
Deep copy of the wrapping ibject in another wrapping object.
- Parameters
-
other The wrapping object to copy
Definition at line 54 of file WrappingObject.cpp.
◆ operator=()
|
inline |
To be able to use the equal "=" operator to define wrapping object.
- Parameters
-
other The 3d node to define the wrapping object
- Returns
- The wrapping object
Definition at line 153 of file WrappingObject.h.
◆ RT() [1/2]
| const utils::RotoTrans & internal_forces::WrappingObject::RT | ( | ) | const |
Return the RotoTrans matrix of the wrapping object.
- Returns
- The RotoTrans matrix of the wrapping object
Definition at line 60 of file WrappingObject.cpp.
◆ RT() [2/2]
|
pure virtual |
Return the RotoTrans matrix of the wrapping object.
- Parameters
-
model The joint model Q The generalized coordinates updateKin If the kinematics should be computed
- Returns
- The RotoTrans matrix of the wrapping object
Implemented in BIORBD_NAMESPACE::internal_forces::WrappingHalfCylinder, and BIORBD_NAMESPACE::internal_forces::WrappingSphere.
◆ wrapPoints() [1/3]
|
pure virtual |
From the position of the wrapping object, return the 2 locations where the muscle leaves the wrapping object.
- Parameters
-
rt RotoTrans matrix of the wrapping object p1_bone 1st position of the muscle node p2_bone 2n position of the muscle node p1 The 1st position on the wrapping object the muscle leave p2 The 2nd position on the wrapping object the muscle leave muscleLength Length of the muscle (ignored if no value is provided)
Implemented in BIORBD_NAMESPACE::internal_forces::WrappingHalfCylinder, and BIORBD_NAMESPACE::internal_forces::WrappingSphere.
◆ wrapPoints() [2/3]
|
pure virtual |
From the position of the wrapping object, return the 2 locations where the muscle leaves the wrapping object.
- Parameters
-
model The joint model Q The generalized coordinates p1_bone 1st position of the muscle node p2_bone 2n position of the muscle node p1 The 1st position on the wrapping object the muscle leave p2 The 2nd position on the wrapping object the muscle leave muscleLength Length of the muscle (ignored if no value is provided)
Implemented in BIORBD_NAMESPACE::internal_forces::WrappingHalfCylinder, and BIORBD_NAMESPACE::internal_forces::WrappingSphere.
◆ wrapPoints() [3/3]
|
pure virtual |
Returns the previously computed 2 locations where the muscle leaves the wrapping object.
- Parameters
-
p1 The 1st position on the wrapping object the muscle leave p2 The 2nd position on the wrapping object the muscle leave muscleLength Length of the muscle (ignored if no value is provided)
Implemented in BIORBD_NAMESPACE::internal_forces::WrappingHalfCylinder, and BIORBD_NAMESPACE::internal_forces::WrappingSphere.
Member Data Documentation
◆ m_RT
|
protected |
RotoTrans matrix of the wrapping object.
Definition at line 160 of file WrappingObject.h.
The documentation for this class was generated from the following files:
