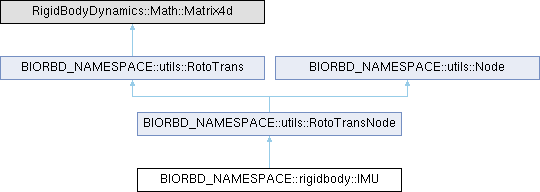
|
| | IMU (bool isTechnical=true, bool isAnatomical=true) |
| | Construct inertial measurement unit.
|
| | IMU (const utils::RotoTransNode &RotoTrans, bool isTechnical=true, bool isAnatomical=true) |
| | Construct inertial measurement unit data.
|
| IMU | DeepCopy () const |
| | Deep copy of the IMU data.
|
| void | DeepCopy (const IMU &other) |
| | Deep copy if the IMU data.
|
| bool | isTechnical () const |
| | Return if the IMU is technical.
|
| bool | isAnatomical () const |
| | Return if the IMU is anatomical.
|
| | RotoTransNode () |
| | Construct a RotoTransNode.
|
| | RotoTransNode (const RotoTrans &rt, const String &name, const String &parentName) |
| | Construct a RotoTransNode.
|
| RotoTransNode | DeepCopy () const |
| | Deep copy of a RotoTransNode.
|
| void | DeepCopy (const RotoTransNode &other) |
| | Deep copy of a RotoTransNode into another RotoTransNode.
|
| void | operator= (const RotoTrans &other) |
| | Assign a RotoTrans to this RotoTransNode (name and parent are reset).
|
| RotoTrans | operator* (const RotoTransNode &other) const |
| | operator* Matrix multiplication
|
| | RotoTrans (const RigidBodyDynamics::Math::Matrix4d &matrix=RigidBodyDynamics::Math::Matrix4d::Identity()) |
| | Construct RotoTrans matrix.
|
| | RotoTrans (const Scalar &v00, const Scalar &v01, const Scalar &v02, const Scalar &v03, const Scalar &v10, const Scalar &v11, const Scalar &v12, const Scalar &v13, const Scalar &v20, const Scalar &v21, const Scalar &v22, const Scalar &v23, const Scalar &v30, const Scalar &v31, const Scalar &v32, const Scalar &v33) |
| | RotoTrans Construct a RotoTrans matrix by elements.
|
| | RotoTrans (const Rotation &rot) |
| | Contruct Rototrans.
|
| | RotoTrans (const Rotation &rot, const Vector3d &trans) |
| | Contruct Rototrans.
|
| | RotoTrans (const Vector &rotation, const Vector3d &translation, const String &rotationSequence) |
| | Contruct Rototrans.
|
| | RotoTrans (const utils::SpatialTransform &st) |
| | Contruct Rototrans.
|
| Vector3d | axe (size_t idx) const |
| | Get a particular axis of the rotation matrix.
|
| RotoTrans | transpose () const |
| | Return the tranposed matrix.
|
| Vector3d | trans () const |
| | Return the translation vector.
|
| Rotation | rot () const |
| | Return the rotation matrix.
|
| void | checkUnitary () |
| | Check if the RotoTrans has a unitary matrix of rotation and the last row is (0, 0, 0, 1).
|
| | Node () |
| | Construct Node.
|
| | Node (const Node &other) |
| | Construct Node from another node.
|
| | Node (const String &name) |
| | Construct Node.
|
| | Node (const String &name, const String &parentName) |
| | Construct Node.
|
| virtual | ~Node () |
| | Destroy class properly.
|
| void | DeepCopy (const Node &other) |
| | Deep copy of the node in another node.
|
| void | setName (const String &name) |
| | Set the name of the node.
|
| const String & | name () const |
| | Return the name of the node.
|
| const String & | parent () const |
| | Return the parent name of the node.
|
| void | setParent (const String &name) |
| | Set the parent name of the node.
|
| NODE_TYPE | typeOfNode () const |
| | Return the type of node.
|
|
| static RotoTrans | fromMarkers (const rigidbody::NodeSegment &origin, const std::pair< rigidbody::NodeSegment, rigidbody::NodeSegment > &axis1markers, const std::pair< rigidbody::NodeSegment, rigidbody::NodeSegment > &axis2markers, const std::pair< String, String > &axesNames, const String &axisToRecalculate) |
| | fromMarkers Creates a system of axes from two axes and an origin defined by markers
|
| static RotoTrans | combineRotAndTrans (const Rotation &rot, const Vector3d &trans) |
| | Set the RotoTrans from a rotation and a translation.
|
| static RotoTrans | fromSpatialTransform (const utils::SpatialTransform &st) |
| | set the RotoTrans from a spatial transform
|
| static RotoTrans | fromEulerAngles (const Vector &rot, const Vector3d &trans, const String &seq) |
| | Create a RotoTrans from Euler angles.
|
| static Vector | toEulerAngles (const RotoTrans &rt, const String &seq) |
| | Return extracted angles from the rotation matrix into Euler angles using the provided sequence.
|
| static utils::RotoTrans | mean (const std::vector< utils::RotoTrans > &rt) |
| | Get the mean of the 4x4 matrices.
|
| void | setType () |
| | Set the type to ROTOTRANS.
|
| RigidBodyDynamics::Math::Vector4d | expand3dTo4d (const Vector3d &v1) |
| | Expand 3D vector to 4D (padding with an extra 1).
|
Class IMU.
Definition at line 23 of file IMU.h.