Loading...
Searching...
No Matches
BIORBD_NAMESPACE::rigidbody::IMUs Class Reference
#include <IMUs.h>
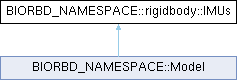
Inheritance diagram for BIORBD_NAMESPACE::rigidbody::IMUs:
Public Member Functions | |
| IMUs () | |
| Construct inertial measurement units set. | |
| IMUs (const IMUs &other) | |
| Construct inertial measurement units set from another set. | |
| virtual | ~IMUs () |
| Destroy the class properly. | |
| IMUs | DeepCopy () const |
| Deep copy of the inertial measurement units data. | |
| void | DeepCopy (const IMUs &other) |
| Deep copy the inertial measurement units data. | |
| void | addIMU (bool technical=true, bool anatomical=true) |
| Add a new inertial measurement unit to the set. | |
| void | addIMU (const utils::RotoTransNode &RotoTrans, bool technical=true, bool anatomical=true) |
| Add a new inertial measurement unit to the set. | |
| size_t | nbIMUs () const |
| Return the number of inertial measurement units (IMU) in the set. | |
| std::vector< utils::String > | IMUsNames () |
| Return the names of the inertial measurement units (IMU). | |
| std::vector< utils::String > | technicalIMUsNames () |
| Return the names of the technical inertial measurement units (IMU). | |
| std::vector< utils::String > | anatomicalIMUsNames () |
| Return the names of the anatomical inertial measurement units (IMU). | |
| const std::vector< rigidbody::IMU > & | IMU () const |
| Return all the IMU in the local reference of the segment. | |
| std::vector< rigidbody::IMU > | IMU (const utils::String &segmentName) |
| Return all the inertial measurement units (IMU) of a segment. | |
| const rigidbody::IMU & | IMU (size_t idx) |
| Return the inertial measurement unit (IMU) of a specified index. | |
| std::vector< rigidbody::IMU > | IMU (const GeneralizedCoordinates &Q, bool updateKin=true) |
| Compute and return all the inertial measurement units (IMU) at the position given by Q. | |
| rigidbody::IMU | IMU (const GeneralizedCoordinates &Q, size_t idx, bool updateKin=true) |
| Compute and return one inertial meausrement unit (IMU) at the position given by Q. | |
| std::vector< rigidbody::IMU > | segmentIMU (const GeneralizedCoordinates &Q, size_t idx, bool updateKin=true) |
| Return all the inertial measurement units (IMU) on a specified segment. | |
| size_t | nbTechIMUs () |
| Return the number of technical inertial measurement units (IMU). | |
| size_t | nbAnatIMUs () |
| Return the number of anatomical inertial measurement units (IMU). | |
| std::vector< rigidbody::IMU > | technicalIMU (const GeneralizedCoordinates &Q, bool updateKin=true) |
| Return all the technical inertial measurement units (IMU). | |
| std::vector< rigidbody::IMU > | technicalIMU () |
| Return all the technical inertial measurement units (IMU) in their respective segment local reference frame. | |
| std::vector< rigidbody::IMU > | anatomicalIMU (const GeneralizedCoordinates &Q, bool updateKin=true) |
| Return all the anatomical inertial measurement units (IMU). | |
| std::vector< rigidbody::IMU > | anatomicalIMU () |
| Return all the anatomical inertial measurement units (IMU) in their respective segment local reference frame. | |
| std::vector< utils::Matrix > | IMUJacobian (const GeneralizedCoordinates &Q, bool updateKin=true) |
| Return the jacobian of the inertial measurement units (IMU). | |
| std::vector< utils::Matrix > | TechnicalIMUJacobian (const GeneralizedCoordinates &Q, bool updateKin=true) |
| Return the jacobian of the technical inertial measurement units (IMU). | |
Protected Member Functions | |
| std::vector< utils::Matrix > | IMUJacobian (const GeneralizedCoordinates &Q, bool updateKin, bool lookForTechnical) |
| Compute and return the jacobian of all the inertial measurement units (IMU). | |
Protected Attributes | |
| std::shared_ptr< std::vector< rigidbody::IMU > > | m_IMUs |
| All the inertial Measurement Units. | |
Detailed Description
Constructor & Destructor Documentation
◆ IMUs() [1/2]
| rigidbody::IMUs::IMUs | ( | ) |
◆ IMUs() [2/2]
| rigidbody::IMUs::IMUs | ( | const IMUs & | other | ) |
◆ ~IMUs()
|
virtual |
Member Function Documentation
◆ addIMU() [1/2]
| void rigidbody::IMUs::addIMU | ( | bool | technical = true, |
| bool | anatomical = true ) |
◆ addIMU() [2/2]
| void rigidbody::IMUs::addIMU | ( | const utils::RotoTransNode & | RotoTrans, |
| bool | technical = true, | ||
| bool | anatomical = true ) |
◆ anatomicalIMU() [1/2]
| std::vector< rigidbody::IMU > rigidbody::IMUs::anatomicalIMU | ( | ) |
◆ anatomicalIMU() [2/2]
| std::vector< rigidbody::IMU > rigidbody::IMUs::anatomicalIMU | ( | const GeneralizedCoordinates & | Q, |
| bool | updateKin = true ) |
◆ anatomicalIMUsNames()
| std::vector< utils::String > rigidbody::IMUs::anatomicalIMUsNames | ( | ) |
◆ DeepCopy() [1/2]
| rigidbody::IMUs rigidbody::IMUs::DeepCopy | ( | ) | const |
◆ DeepCopy() [2/2]
| void rigidbody::IMUs::DeepCopy | ( | const IMUs & | other | ) |
◆ IMU() [1/5]
| const std::vector< rigidbody::IMU > & rigidbody::IMUs::IMU | ( | ) | const |
◆ IMU() [2/5]
| std::vector< rigidbody::IMU > rigidbody::IMUs::IMU | ( | const GeneralizedCoordinates & | Q, |
| bool | updateKin = true ) |
◆ IMU() [3/5]
| rigidbody::IMU rigidbody::IMUs::IMU | ( | const GeneralizedCoordinates & | Q, |
| size_t | idx, | ||
| bool | updateKin = true ) |
◆ IMU() [4/5]
| std::vector< rigidbody::IMU > rigidbody::IMUs::IMU | ( | const utils::String & | segmentName | ) |
◆ IMU() [5/5]
| const rigidbody::IMU & rigidbody::IMUs::IMU | ( | size_t | idx | ) |
◆ IMUJacobian() [1/2]
|
protected |
◆ IMUJacobian() [2/2]
| std::vector< utils::Matrix > rigidbody::IMUs::IMUJacobian | ( | const GeneralizedCoordinates & | Q, |
| bool | updateKin = true ) |
◆ IMUsNames()
| std::vector< utils::String > rigidbody::IMUs::IMUsNames | ( | ) |
◆ nbAnatIMUs()
| size_t rigidbody::IMUs::nbAnatIMUs | ( | ) |
◆ nbIMUs()
| size_t rigidbody::IMUs::nbIMUs | ( | ) | const |
◆ nbTechIMUs()
| size_t rigidbody::IMUs::nbTechIMUs | ( | ) |
◆ segmentIMU()
| std::vector< rigidbody::IMU > rigidbody::IMUs::segmentIMU | ( | const GeneralizedCoordinates & | Q, |
| size_t | idx, | ||
| bool | updateKin = true ) |
◆ technicalIMU() [1/2]
| std::vector< rigidbody::IMU > rigidbody::IMUs::technicalIMU | ( | ) |
◆ technicalIMU() [2/2]
| std::vector< rigidbody::IMU > rigidbody::IMUs::technicalIMU | ( | const GeneralizedCoordinates & | Q, |
| bool | updateKin = true ) |
◆ TechnicalIMUJacobian()
| std::vector< utils::Matrix > rigidbody::IMUs::TechnicalIMUJacobian | ( | const GeneralizedCoordinates & | Q, |
| bool | updateKin = true ) |
◆ technicalIMUsNames()
| std::vector< utils::String > rigidbody::IMUs::technicalIMUsNames | ( | ) |
Member Data Documentation
◆ m_IMUs
|
protected |
The documentation for this class was generated from the following files:
