Loading...
Searching...
No Matches
BIORBD_NAMESPACE::rigidbody::SoftContactSphere Class Reference
A point attached to a contact node, generally speaking a skin marker. More...
#include <SoftContactSphere.h>
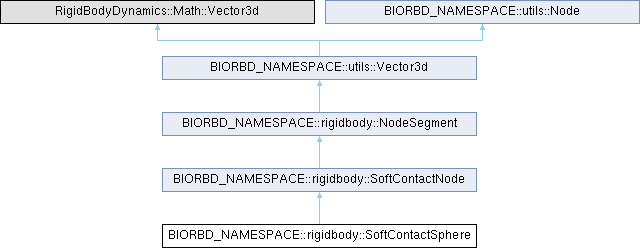
Inheritance diagram for BIORBD_NAMESPACE::rigidbody::SoftContactSphere:
Public Member Functions | |
| SoftContactSphere () | |
| Construct a contact node. | |
| SoftContactSphere (const rigidbody::SoftContactNode &other) | |
| Construct a contact node. | |
| SoftContactSphere (const utils::Scalar &x, const utils::Scalar &y, const utils::Scalar &z, const utils::Scalar &radius, const utils::Scalar &stiffness, const utils::Scalar &damping, const utils::Scalar &muStatic, const utils::Scalar &muDynamic, const utils::Scalar &muViscous) | |
| Construct a contact node. | |
| SoftContactSphere (const utils::Vector3d &other, const utils::Scalar &radius, const utils::Scalar &stiffness, const utils::Scalar &damping, const utils::Scalar &muStatic, const utils::Scalar &muDynamic, const utils::Scalar &muViscous) | |
| Construct a contact node from another node. | |
| SoftContactSphere (const utils::Scalar &x, const utils::Scalar &y, const utils::Scalar &z, const utils::Scalar &radius, const utils::Scalar &stiffness, const utils::Scalar &damping, const utils::Scalar &muStatic, const utils::Scalar &muDynamic, const utils::Scalar &muViscous, const utils::String &name, const utils::String &parentName, int parentID) | |
| Construct a contact node. | |
| SoftContactSphere (const utils::Vector3d &node, const utils::Scalar &radius, const utils::Scalar &stiffness, const utils::Scalar &damping, const utils::Scalar &muStatic, const utils::Scalar &muDynamic, const utils::Scalar &muViscous, const utils::String &name, const utils::String &parentName, int parentID) | |
| Construct a contact node. | |
| SoftContactSphere | DeepCopy () const |
| Deep copy of the contact node. | |
| void | DeepCopy (const SoftContactSphere &other) |
| Deep copy of the contact node. | |
| void | setRadius (const utils::Scalar &radius) |
| Set a new value for the radius. | |
| utils::Scalar | radius () const |
| Return the value of the radius. | |
| void | setStiffness (const utils::Scalar &stiffness) |
| Set a new value for the stiffness. | |
| utils::Scalar | stiffness () const |
| Return the value of the stiffness. | |
| void | setDamping (const utils::Scalar &damping) |
| Set a new value for the damping. | |
| utils::Scalar | damping () const |
| Return the value of the damping. | |
| void | setMuStatic (const utils::Scalar &muStatic) |
| Set a new value for the muStatic. | |
| utils::Scalar | muStatic () const |
| Return the value of the muStatic. | |
| void | setMuDynamic (const utils::Scalar &muDynamic) |
| Set a new value for the muDynamic. | |
| utils::Scalar | muDynamic () const |
| Return the value of the muDynamic. | |
| void | setMuViscous (const utils::Scalar &muViscous) |
| Set a new value for the muViscous. | |
| utils::Scalar | muViscous () const |
| Return the value of the muViscous. | |
| void | setTransitionVelocity (const utils::Scalar &transitionVelocity) |
| Set a new value for the transitionVelocity. | |
| utils::Scalar | transitionVelocity () const |
| Return the value of the transitionVelocity. | |
| virtual utils::Vector3d | computeForce (const utils::Vector3d &x, const utils::Vector3d &dx, const utils::Vector3d &angularVelocity) const |
| Get the force in a spatial vector at the center of mass of the underlying segment. | |
| virtual utils::Vector3d | applicationPoint (const utils::Vector3d &x) const |
| Get the application point relative to the plane. | |
| Public Member Functions inherited from BIORBD_NAMESPACE::rigidbody::SoftContactNode | |
| SoftContactNode () | |
| Construct a contact node. | |
| SoftContactNode (const utils::Scalar &x, const utils::Scalar &y, const utils::Scalar &z) | |
| Construct a contact node. | |
| SoftContactNode (const utils::Vector3d &other) | |
| Construct a contact node from another node. | |
| SoftContactNode (const utils::Scalar &x, const utils::Scalar &y, const utils::Scalar &z, const utils::String &name, const utils::String &parentName, int parentID) | |
| Construct a contact node. | |
| SoftContactNode (const utils::Vector3d &node, const utils::String &name, const utils::String &parentName, int parentID) | |
| Construct a contact node. | |
| void | DeepCopy (const SoftContactNode &other) |
| Deep copy of the contact node. | |
| virtual utils::SpatialVector | computeForceAtOrigin (Joints &model, const GeneralizedCoordinates &Q, const GeneralizedVelocity &Qdot, bool updateKin=true) |
| Get the force in a spatial vector at the origin of the world base coordinates. | |
| Public Member Functions inherited from BIORBD_NAMESPACE::rigidbody::NodeSegment | |
| NodeSegment () | |
| Construct a segment node. | |
| NodeSegment (const utils::Scalar &x, const utils::Scalar &y, const utils::Scalar &z) | |
| Construct a segment node. | |
| NodeSegment (const utils::Vector3d &other) | |
| Construct a segment node from another node. | |
| NodeSegment (const utils::Scalar &x, const utils::Scalar &y, const utils::Scalar &z, const utils::String &name, const utils::String &parentName, bool isTechnical, bool isAnatomical, const utils::String &axesToRemove, int parentID) | |
| Construct a segment node. | |
| NodeSegment (const utils::Vector3d &node, const utils::String &name, const utils::String &parentName, bool isTechnical, bool isAnatomical, const utils::String &axesToRemove, int parentID) | |
| Construct a segment node. | |
| NodeSegment | DeepCopy () const |
| Deep copy of the segment node. | |
| void | DeepCopy (const NodeSegment &other) |
| Deep copy of the segment node. | |
| void | setValues (const NodeSegment &values) |
| Set internal values of the node without changing other parameters. | |
| bool | isTechnical () const |
| Return if node is technical. | |
| bool | isAnatomical () const |
| Return if node is anatomical. | |
| int | parentId () const |
| Return the parent index. | |
| const std::vector< bool > & | axesToRemove () const |
| Accessor to axes to remove. | |
| const std::vector< bool > | axes () const |
| A vector of bool which is the opposite of axesToRemove. | |
| NodeSegment | removeAxes () const |
| To remove axis. | |
| bool | isAxisRemoved (size_t i) const |
| Check if axis is removed. | |
| bool | isAxisKept (size_t i) const |
| Check if axis is kept. | |
| std::vector< int > | availableAxesIndices () const |
| Get all the indices of the axes to keep (X=0, Y=1, Z=2). | |
| void | addAxesToRemove (size_t axisNumber) |
| Add an axis to remove. | |
| void | addAxesToRemove (const utils::String &axis) |
| Add axis to remove. | |
| void | addAxesToRemove (const std::vector< size_t > &axes) |
| Add multiple axes to remove. | |
| void | addAxesToRemove (const std::vector< utils::String > &axes) |
| Add multiple axes to remove. | |
| utils::String | axesToRemoveAsString () const |
| Return the axes to removed. | |
| int | nbAxesToRemove () const |
| Return the number of axes to remove. | |
| Public Member Functions inherited from BIORBD_NAMESPACE::utils::Vector3d | |
| Vector3d () | |
| Construct 3D vector. | |
| Vector3d (const Scalar &x, const Scalar &y, const Scalar &z) | |
| Construct 3D vector. | |
| Vector3d (const Scalar &x, const Scalar &y, const Scalar &z, const String &name, const String &parentName) | |
| Construct a 3D vector. | |
| Vector3d (const Vector3d vec, const String &name, const String &parentName) | |
| Construct a 3D vector. | |
| Vector3d (const RigidBodyDynamics::Math::Vector3d &other) | |
| Construct a 3D vector from a Casadi 3D vector (drop the trailling 1). | |
| Vector3d (const RigidBodyDynamics::Math::VectorNd &other) | |
| Construct a 3D vector from a Casadi ND vector (drop the trailling 1). | |
| Vector3d (const RigidBodyDynamics::Math::Vector4d &other) | |
| Construct a 3D vector from an eigen 4D vector (drop the trailling 1). | |
| Vector3d | DeepCopy () const |
| Deep copy of a 3D vector. | |
| void | DeepCopy (const Vector3d &other) |
| Deep copy of a 3D vector into another 3D vector. | |
| Vector3d | applyRT (const RotoTrans &rt) const |
| Apply a RotoTrans to the 3D vector. | |
| void | applyRT (const RotoTrans &rt) |
| Apply a RotoTrans to the 3D vector. | |
| void | setPosition (const Vector3d &v) |
| Set a new position. | |
| Public Member Functions inherited from BIORBD_NAMESPACE::utils::Node | |
| Node () | |
| Construct Node. | |
| Node (const Node &other) | |
| Construct Node from another node. | |
| Node (const String &name) | |
| Construct Node. | |
| Node (const String &name, const String &parentName) | |
| Construct Node. | |
| virtual | ~Node () |
| Destroy class properly. | |
| void | DeepCopy (const Node &other) |
| Deep copy of the node in another node. | |
| void | setName (const String &name) |
| Set the name of the node. | |
| const String & | name () const |
| Return the name of the node. | |
| const String & | parent () const |
| Return the parent name of the node. | |
| void | setParent (const String &name) |
| Set the parent name of the node. | |
| NODE_TYPE | typeOfNode () const |
| Return the type of node. | |
Protected Member Functions | |
| void | setType () |
| Set the type of the contact node. | |
| Protected Member Functions inherited from BIORBD_NAMESPACE::utils::Vector3d | |
| void | setType () |
| Set the type Vector3d. | |
Protected Attributes | |
| std::shared_ptr< utils::Scalar > | m_radius |
| The radius of the contact sphere. | |
| std::shared_ptr< utils::Scalar > | m_stiffness |
| The stiffness of the contact sphere. | |
| std::shared_ptr< utils::Scalar > | m_damping |
| The damping factor of the contact sphere. | |
| std::shared_ptr< utils::Scalar > | m_muStatic |
| Static coefficient of friction (mu). | |
| std::shared_ptr< utils::Scalar > | m_muDynamic |
| Dynamic coefficient of friction (mu). | |
| std::shared_ptr< utils::Scalar > | m_muViscous |
| Vicous coefficient of friction (mu). | |
| std::shared_ptr< utils::Scalar > | m_transitionVelocity |
| Protected Attributes inherited from BIORBD_NAMESPACE::rigidbody::SoftContactNode | |
| std::shared_ptr< std::pair< utils::Vector3d, utils::Vector3d > > | m_contactPlane |
| Protected Attributes inherited from BIORBD_NAMESPACE::rigidbody::NodeSegment | |
| std::shared_ptr< std::vector< bool > > | m_axesRemoved |
| The axes to remove. | |
| std::shared_ptr< int > | m_nbAxesToRemove |
| std::shared_ptr< bool > | m_technical |
| If a marker is a technical marker. | |
| std::shared_ptr< bool > | m_anatomical |
| It marker is a anatomical marker. | |
| std::shared_ptr< int > | m_id |
| The parent identification. | |
| Protected Attributes inherited from BIORBD_NAMESPACE::utils::Node | |
| std::shared_ptr< String > | m_name |
| The name of the node. | |
| std::shared_ptr< String > | m_parentName |
| The parent name of the node. | |
| std::shared_ptr< NODE_TYPE > | m_typeOfNode |
| The type of the node. | |
Detailed Description
A point attached to a contact node, generally speaking a skin marker.
Definition at line 15 of file SoftContactSphere.h.
Constructor & Destructor Documentation
◆ SoftContactSphere() [1/6]
| rigidbody::SoftContactSphere::SoftContactSphere | ( | ) |
Construct a contact node.
Definition at line 8 of file SoftContactSphere.cpp.
◆ SoftContactSphere() [2/6]
| rigidbody::SoftContactSphere::SoftContactSphere | ( | const rigidbody::SoftContactNode & | other | ) |
Construct a contact node.
- Parameters
-
other The contact node to copy
Definition at line 20 of file SoftContactSphere.cpp.
◆ SoftContactSphere() [3/6]
| rigidbody::SoftContactSphere::SoftContactSphere | ( | const utils::Scalar & | x, |
| const utils::Scalar & | y, | ||
| const utils::Scalar & | z, | ||
| const utils::Scalar & | radius, | ||
| const utils::Scalar & | stiffness, | ||
| const utils::Scalar & | damping, | ||
| const utils::Scalar & | muStatic, | ||
| const utils::Scalar & | muDynamic, | ||
| const utils::Scalar & | muViscous ) |
Construct a contact node.
- Parameters
-
x X-Component of the node y Y-Component of the node z Z-Component of the node radius The radius of the sphere stiffness The stiffness of the contact sphere damping The damping factor of the contact sphere muStatic Static friction coefficient muDynamic Dynamic friction coefficient muViscous Viscous friction coefficient
Definition at line 37 of file SoftContactSphere.cpp.
◆ SoftContactSphere() [4/6]
| rigidbody::SoftContactSphere::SoftContactSphere | ( | const utils::Vector3d & | other, |
| const utils::Scalar & | radius, | ||
| const utils::Scalar & | stiffness, | ||
| const utils::Scalar & | damping, | ||
| const utils::Scalar & | muStatic, | ||
| const utils::Scalar & | muDynamic, | ||
| const utils::Scalar & | muViscous ) |
Construct a contact node from another node.
- Parameters
-
other The other node radius The radius of the sphere stiffness The stiffness of the contact sphere damping The damping factor of the contact sphere muStatic Static friction coefficient muDynamic Dynamic friction coefficient muViscous Viscous friction coefficient
Definition at line 58 of file SoftContactSphere.cpp.
◆ SoftContactSphere() [5/6]
| rigidbody::SoftContactSphere::SoftContactSphere | ( | const utils::Scalar & | x, |
| const utils::Scalar & | y, | ||
| const utils::Scalar & | z, | ||
| const utils::Scalar & | radius, | ||
| const utils::Scalar & | stiffness, | ||
| const utils::Scalar & | damping, | ||
| const utils::Scalar & | muStatic, | ||
| const utils::Scalar & | muDynamic, | ||
| const utils::Scalar & | muViscous, | ||
| const utils::String & | name, | ||
| const utils::String & | parentName, | ||
| int | parentID ) |
Construct a contact node.
- Parameters
-
x X-Component of the node y Y-Component of the node z Z-Component of the node radius The radius of the sphere stiffness The stiffness of the contact sphere damping The damping factor of the contact sphere muStatic Static friction coefficient muDynamic Dynamic friction coefficient muViscous Viscous friction coefficient name The name of the node parentName The name of the parent parentID The index of the parent contact
Definition at line 77 of file SoftContactSphere.cpp.
◆ SoftContactSphere() [6/6]
| rigidbody::SoftContactSphere::SoftContactSphere | ( | const utils::Vector3d & | node, |
| const utils::Scalar & | radius, | ||
| const utils::Scalar & | stiffness, | ||
| const utils::Scalar & | damping, | ||
| const utils::Scalar & | muStatic, | ||
| const utils::Scalar & | muDynamic, | ||
| const utils::Scalar & | muViscous, | ||
| const utils::String & | name, | ||
| const utils::String & | parentName, | ||
| int | parentID ) |
Construct a contact node.
- Parameters
-
node The position of the node radius The radius of the sphere stiffness The stiffness of the contact sphere damping The damping factor of the contact sphere muStatic Static friction coefficient muDynamic Dynamic friction coefficient muViscous Viscous friction coefficient name The name of the node parentName The name of the parent parentID The index of the parent contact
Definition at line 101 of file SoftContactSphere.cpp.
Member Function Documentation
◆ applicationPoint()
|
virtual |
Get the application point relative to the plane.
- Parameters
-
x The position of the contact in global reference frame
- Returns
- The application point
Implements BIORBD_NAMESPACE::rigidbody::SoftContactNode.
Definition at line 251 of file SoftContactSphere.cpp.
◆ computeForce()
|
virtual |
Get the force in a spatial vector at the center of mass of the underlying segment.
- Parameters
-
x The position of the contact in global reference frame dx The velocity of the contact in global reference frame angularVelocity The angular velocity of the segment in global reference frame with respect to the global frame.
- Returns
- The Spatial vector
Implements BIORBD_NAMESPACE::rigidbody::SoftContactNode.
Definition at line 198 of file SoftContactSphere.cpp.
◆ damping()
| utils::Scalar rigidbody::SoftContactSphere::damping | ( | ) | const |
Return the value of the damping.
- Returns
- The value of the damping
Definition at line 159 of file SoftContactSphere.cpp.
◆ DeepCopy() [1/2]
| rigidbody::SoftContactSphere rigidbody::SoftContactSphere::DeepCopy | ( | ) | const |
Deep copy of the contact node.
- Returns
- A deep copy of the contact node
Definition at line 123 of file SoftContactSphere.cpp.
◆ DeepCopy() [2/2]
| void rigidbody::SoftContactSphere::DeepCopy | ( | const SoftContactSphere & | other | ) |
Deep copy of the contact node.
- Parameters
-
other The contact node to copy
Definition at line 129 of file SoftContactSphere.cpp.
◆ muDynamic()
| utils::Scalar rigidbody::SoftContactSphere::muDynamic | ( | ) | const |
Return the value of the muDynamic.
- Returns
- The value of the muDynamic
Definition at line 176 of file SoftContactSphere.cpp.
◆ muStatic()
| utils::Scalar rigidbody::SoftContactSphere::muStatic | ( | ) | const |
Return the value of the muStatic.
- Returns
- The value of the muStatic
Definition at line 167 of file SoftContactSphere.cpp.
◆ muViscous()
| utils::Scalar rigidbody::SoftContactSphere::muViscous | ( | ) | const |
Return the value of the muViscous.
- Returns
- The value of the muViscous
Definition at line 185 of file SoftContactSphere.cpp.
◆ radius()
| utils::Scalar rigidbody::SoftContactSphere::radius | ( | ) | const |
Return the value of the radius.
- Returns
- The value of the radius
Definition at line 144 of file SoftContactSphere.cpp.
◆ setDamping()
| void rigidbody::SoftContactSphere::setDamping | ( | const utils::Scalar & | damping | ) |
Set a new value for the damping.
- Parameters
-
damping The new value for the damping
Definition at line 155 of file SoftContactSphere.cpp.
◆ setMuDynamic()
| void rigidbody::SoftContactSphere::setMuDynamic | ( | const utils::Scalar & | muDynamic | ) |
Set a new value for the muDynamic.
- Parameters
-
muDynamic The new value for the muDynamic
Definition at line 171 of file SoftContactSphere.cpp.
◆ setMuStatic()
| void rigidbody::SoftContactSphere::setMuStatic | ( | const utils::Scalar & | muStatic | ) |
Set a new value for the muStatic.
- Parameters
-
muStatic The new value for the muStatic
Definition at line 163 of file SoftContactSphere.cpp.
◆ setMuViscous()
| void rigidbody::SoftContactSphere::setMuViscous | ( | const utils::Scalar & | muViscous | ) |
Set a new value for the muViscous.
- Parameters
-
muViscous The new value for the muViscous
Definition at line 180 of file SoftContactSphere.cpp.
◆ setRadius()
| void rigidbody::SoftContactSphere::setRadius | ( | const utils::Scalar & | radius | ) |
Set a new value for the radius.
- Parameters
-
radius The new value for the radius
Definition at line 140 of file SoftContactSphere.cpp.
◆ setStiffness()
| void rigidbody::SoftContactSphere::setStiffness | ( | const utils::Scalar & | stiffness | ) |
Set a new value for the stiffness.
- Parameters
-
stiffness The new value for the stiffness
Definition at line 146 of file SoftContactSphere.cpp.
◆ setTransitionVelocity()
| void rigidbody::SoftContactSphere::setTransitionVelocity | ( | const utils::Scalar & | transitionVelocity | ) |
Set a new value for the transitionVelocity.
- Parameters
-
transitionVelocity The new value for the transitionVelocity
Definition at line 189 of file SoftContactSphere.cpp.
◆ setType()
|
protectedvirtual |
Set the type of the contact node.
Reimplemented from BIORBD_NAMESPACE::rigidbody::SoftContactNode.
Definition at line 260 of file SoftContactSphere.cpp.
◆ stiffness()
| utils::Scalar rigidbody::SoftContactSphere::stiffness | ( | ) | const |
Return the value of the stiffness.
- Returns
- The value of the stiffness
Definition at line 151 of file SoftContactSphere.cpp.
◆ transitionVelocity()
| utils::Scalar rigidbody::SoftContactSphere::transitionVelocity | ( | ) | const |
Return the value of the transitionVelocity.
- Returns
- The value of the transitionVelocity
Definition at line 194 of file SoftContactSphere.cpp.
Member Data Documentation
◆ m_damping
|
protected |
The damping factor of the contact sphere.
Definition at line 252 of file SoftContactSphere.h.
◆ m_muDynamic
|
protected |
Dynamic coefficient of friction (mu).
Definition at line 257 of file SoftContactSphere.h.
◆ m_muStatic
|
protected |
Static coefficient of friction (mu).
Definition at line 255 of file SoftContactSphere.h.
◆ m_muViscous
|
protected |
Vicous coefficient of friction (mu).
Definition at line 259 of file SoftContactSphere.h.
◆ m_radius
|
protected |
The radius of the contact sphere.
Definition at line 248 of file SoftContactSphere.h.
◆ m_stiffness
|
protected |
The stiffness of the contact sphere.
Definition at line 250 of file SoftContactSphere.h.
◆ m_transitionVelocity
|
protected |
Transition velocity factor of Hunt-Crossley's model
Definition at line 261 of file SoftContactSphere.h.
The documentation for this class was generated from the following files:
