Loading...
Searching...
No Matches
BIORBD_NAMESPACE::internal_forces::muscles::IdealizedActuator Class Reference
Muscle that has a constant maximal force. More...
#include <IdealizedActuator.h>
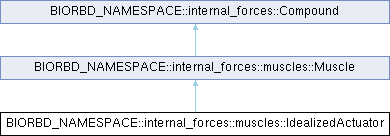
Inheritance diagram for BIORBD_NAMESPACE::internal_forces::muscles::IdealizedActuator:
Public Member Functions | |
| IdealizedActuator () | |
| Contruct an idealized actuator. | |
| IdealizedActuator (const utils::String &name, const MuscleGeometry &geometry, const Characteristics &characteristics) | |
| Construct an idealized actuator. | |
| IdealizedActuator (const utils::String &name, const MuscleGeometry &geometry, const Characteristics &characteristics, const State &emg) | |
| Construct an idealized actuator. | |
| IdealizedActuator (const utils::String &name, const MuscleGeometry &geometry, const Characteristics &characteristics, const internal_forces::PathModifiers &pathModifiers) | |
| Construct an idealized actuator. | |
| IdealizedActuator (const utils::String &name, const MuscleGeometry &geometry, const Characteristics &characteristics, const internal_forces::PathModifiers &pathModifiers, const State &emg) | |
| Construct an idealized actuator. | |
| IdealizedActuator (const Muscle &other) | |
| Construct an idealized actuator from another muscle. | |
| IdealizedActuator (const std::shared_ptr< Muscle > other) | |
| Construct an idealized actuator from another muscle. | |
| IdealizedActuator | DeepCopy () const |
| Deep copy of an idealized actuator. | |
| void | DeepCopy (const IdealizedActuator &other) |
| Deep copy of an idealized actuator from another idealized actuator. | |
| virtual const utils::Scalar & | force (const State &emg) |
| Return the force. | |
| virtual const utils::Scalar & | force (rigidbody::Joints &model, const rigidbody::GeneralizedCoordinates &Q, const rigidbody::GeneralizedVelocity &Qdot, const State &emg, bool updateMuscleParameters=true) |
| Return the muscle force vector at origin and insertion. | |
| virtual const utils::Scalar & | force (rigidbody::Joints &model, const rigidbody::GeneralizedCoordinates &Q, const State &emg, bool updateMuscleParameters=true) |
| Return the muscle force vector at origin and insertion. | |
| Public Member Functions inherited from BIORBD_NAMESPACE::internal_forces::muscles::Muscle | |
| Muscle () | |
| Construct a muscle. | |
| Muscle (const utils::String &name, const internal_forces::muscles::MuscleGeometry &position, const Characteristics &characteristics) | |
| Construct a muscle. | |
| Muscle (const utils::String &name, const internal_forces::muscles::MuscleGeometry &position, const Characteristics &characteristics, const State &emg) | |
| Construct a muscle. | |
| Muscle (const utils::String &name, const internal_forces::muscles::MuscleGeometry &position, const Characteristics &characteristics, const internal_forces::PathModifiers &pathModifiers) | |
| Construct a muscle. | |
| Muscle (const utils::String &name, const internal_forces::muscles::MuscleGeometry &position, const Characteristics &characteristics, const internal_forces::PathModifiers &pathModifiers, const State &emg) | |
| Construct a muscle. | |
| Muscle (const Muscle &other) | |
| Construct a muscle from another muscle. | |
| Muscle (const std::shared_ptr< Muscle > other) | |
| Construct a muscle from another muscle. | |
| virtual | ~Muscle () |
| Destroy class properly. | |
| void | DeepCopy (const Muscle &other) |
| Deep copy of a muscle in new muscle. | |
| const utils::Scalar & | length (rigidbody::Joints &updatedModel, const rigidbody::GeneralizedCoordinates &Q, bool updateMuscleParameters=true) |
| Get the length of the muscle. | |
| const utils::Scalar & | musculoTendonLength (rigidbody::Joints &updatedModel, const rigidbody::GeneralizedCoordinates &Q, bool updateMuscleParameters=true) |
| Return the musculo tendon length. | |
| const utils::Scalar & | velocity (rigidbody::Joints &updatedModel, const rigidbody::GeneralizedCoordinates &Q, const rigidbody::GeneralizedVelocity &Qdot, bool updateMuscleParameters=true) |
| Return the velocity of the muscle. | |
| void | updateOrientations (rigidbody::Joints &updatedModel, const rigidbody::GeneralizedCoordinates &Q) |
| Update the position of the origin and insertion positions of the muscle. | |
| void | updateOrientations (rigidbody::Joints &updatedModel, const rigidbody::GeneralizedCoordinates &Q, const rigidbody::GeneralizedVelocity &Qdot) |
| Update the position of the origin and insertion nodes of the muscle. | |
| void | updateOrientations (std::vector< utils::Vector3d > &musclePointsInGlobal, utils::Matrix &jacoPointsInGlobal) |
| Update by hand the position of the origin and insertion nodes of the muscle. | |
| void | updateOrientations (std::vector< utils::Vector3d > &musclePointsInGlobal, utils::Matrix &jacoPointsInGlobal, const rigidbody::GeneralizedVelocity &Qdot) |
| Update by hand the position of the origin and insertion nodes of the muscle. | |
| void | setPosition (const internal_forces::muscles::MuscleGeometry &positions) |
| Set the position of all the points attached to the muscle (0 being the origin). | |
| const internal_forces::muscles::MuscleGeometry & | position () const |
| Return the position of all the points attached to the muscle (0 being the origin). | |
| void | setCharacteristics (const Characteristics &characteristics) |
| Set the muscle characteristics. | |
| Characteristics & | characteristics () const |
| Return the muscle characteristics. | |
| const std::vector< utils::Vector3d > & | musclesPointsInGlobal (rigidbody::Joints &updatedModel, const rigidbody::GeneralizedCoordinates &Q, bool updateMuscleParameters=true) |
| Return the muscle points in global reference frame. | |
| const std::vector< utils::Vector3d > & | musclesPointsInGlobal () const |
| Return the previously computed muscle points in global reference frame. | |
| void | setForceIsoMax (const utils::Scalar &forceMax) |
| Set the maximal isometric force. | |
| void | setState (const State &emg) |
| Set the dynamic state. | |
| const State & | state () const |
| Return the dynamic state. | |
| State & | state () |
| Return the dynamic state. | |
| const utils::Scalar & | activationDot (const State &state, bool alreadyNormalized=false) const |
| Return the activation time derivative. | |
| MUSCLE_TYPE | type () const |
| Return the type of the muscle. | |
| Public Member Functions inherited from BIORBD_NAMESPACE::internal_forces::Compound | |
| Compound () | |
| Construct muscle compound. | |
| Compound (const utils::String &name) | |
| Construct compound. | |
| Compound (const utils::String &name, const internal_forces::PathModifiers &pathModifiers) | |
| Construct compound. | |
| Compound (const Compound &other) | |
| Construct compound from another muscle. | |
| Compound (const std::shared_ptr< Compound > other) | |
| Construct compound from another compound. | |
| virtual | ~Compound () |
| Destroy class properly. | |
| void | DeepCopy (const Compound &other) |
| Deep copy of a compound. | |
| void | setName (const utils::String &name) |
| Set the name of a muscle. | |
| const utils::String & | name () const |
| Return the name of the muscle. | |
| const internal_forces::PathModifiers & | pathModifier () |
| Return the path modifier. | |
| void | addPathObject (utils::Vector3d &wrap) |
| Add a path modifier object. | |
| virtual const utils::Scalar & | force () |
| Return the last computed muscle force norm. | |
Protected Member Functions | |
| virtual utils::Scalar | getForceFromActivation (const State &emg) |
| Function allowing modification of the way the multiplication is done in computeForce(EMG). | |
| virtual void | setType () |
| Set the type to Idealized_actuator. | |
| Protected Member Functions inherited from BIORBD_NAMESPACE::internal_forces::muscles::Muscle | |
| virtual void | computeForce (const State &emg) |
| Computer the forces from a specific emg. | |
Additional Inherited Members | |
| Protected Attributes inherited from BIORBD_NAMESPACE::internal_forces::muscles::Muscle | |
| std::shared_ptr< MUSCLE_TYPE > | m_type |
| The type of the muscle. | |
| std::shared_ptr< internal_forces::muscles::MuscleGeometry > | m_position |
| The geometry (position of the nodes) of the muscle. | |
| std::shared_ptr< Characteristics > | m_characteristics |
| The muscle characteristics. | |
| std::shared_ptr< State > | m_state |
| The dynamic state. | |
| std::shared_ptr< utils::Scalar > | m_muscleLength |
| muscle tendon length | |
| Protected Attributes inherited from BIORBD_NAMESPACE::internal_forces::Compound | |
| std::shared_ptr< utils::String > | m_name |
| The name of the muscle. | |
| std::shared_ptr< internal_forces::PathModifiers > | m_pathChanger |
| The set of path modifiers. | |
| std::shared_ptr< utils::Scalar > | m_force |
| The last computed force. | |
Detailed Description
Muscle that has a constant maximal force.
Definition at line 15 of file IdealizedActuator.h.
Constructor & Destructor Documentation
◆ IdealizedActuator() [1/7]
| internal_forces::muscles::IdealizedActuator::IdealizedActuator | ( | ) |
Contruct an idealized actuator.
Definition at line 10 of file IdealizedActuator.cpp.
◆ IdealizedActuator() [2/7]
| internal_forces::muscles::IdealizedActuator::IdealizedActuator | ( | const utils::String & | name, |
| const MuscleGeometry & | geometry, | ||
| const Characteristics & | characteristics ) |
Construct an idealized actuator.
- Parameters
-
name The name of the muscle geometry The muscle geometry characteristics The muscle characteristics
Definition at line 15 of file IdealizedActuator.cpp.
◆ IdealizedActuator() [3/7]
| internal_forces::muscles::IdealizedActuator::IdealizedActuator | ( | const utils::String & | name, |
| const MuscleGeometry & | geometry, | ||
| const Characteristics & | characteristics, | ||
| const State & | emg ) |
Construct an idealized actuator.
- Parameters
-
name The name of the muscle geometry The muscle geometry characteristics The muscle characteristics emg The muscle dynamic state
Definition at line 23 of file IdealizedActuator.cpp.
◆ IdealizedActuator() [4/7]
| internal_forces::muscles::IdealizedActuator::IdealizedActuator | ( | const utils::String & | name, |
| const MuscleGeometry & | geometry, | ||
| const Characteristics & | characteristics, | ||
| const internal_forces::PathModifiers & | pathModifiers ) |
Construct an idealized actuator.
- Parameters
-
name The name of the muscle geometry The muscle geometry characteristics The muscle characteristics pathModifiers The set of path modifiers
Definition at line 32 of file IdealizedActuator.cpp.
◆ IdealizedActuator() [5/7]
| internal_forces::muscles::IdealizedActuator::IdealizedActuator | ( | const utils::String & | name, |
| const MuscleGeometry & | geometry, | ||
| const Characteristics & | characteristics, | ||
| const internal_forces::PathModifiers & | pathModifiers, | ||
| const State & | emg ) |
Construct an idealized actuator.
- Parameters
-
name The name of the muscle geometry The muscle geometry characteristics The muscle characteristics pathModifiers The set of path modifiers emg The dynamic state
Definition at line 45 of file IdealizedActuator.cpp.
◆ IdealizedActuator() [6/7]
| internal_forces::muscles::IdealizedActuator::IdealizedActuator | ( | const Muscle & | other | ) |
Construct an idealized actuator from another muscle.
- Parameters
-
other The other muscle
Definition at line 60 of file IdealizedActuator.cpp.
◆ IdealizedActuator() [7/7]
| internal_forces::muscles::IdealizedActuator::IdealizedActuator | ( | const std::shared_ptr< Muscle > | other | ) |
Construct an idealized actuator from another muscle.
- Parameters
-
other The other muscle
Definition at line 64 of file IdealizedActuator.cpp.
Member Function Documentation
◆ DeepCopy() [1/2]
| internal_forces::muscles::IdealizedActuator internal_forces::muscles::IdealizedActuator::DeepCopy | ( | ) | const |
Deep copy of an idealized actuator.
- Returns
- A deep copy of an idealized actuator
Definition at line 69 of file IdealizedActuator.cpp.
◆ DeepCopy() [2/2]
| void internal_forces::muscles::IdealizedActuator::DeepCopy | ( | const IdealizedActuator & | other | ) |
Deep copy of an idealized actuator from another idealized actuator.
- Parameters
-
other The idealized actuator to copy
Definition at line 75 of file IdealizedActuator.cpp.
◆ force() [1/3]
|
virtual |
Return the force.
- Parameters
-
emg EMG data
- Returns
- The force
Implements BIORBD_NAMESPACE::internal_forces::muscles::Muscle.
Definition at line 80 of file IdealizedActuator.cpp.
◆ force() [2/3]
|
virtual |
Return the muscle force vector at origin and insertion.
- Parameters
-
model The joint model previously updated to the proper level Q The generalized coordinates Qdot The generalized velocities emg The EMG data updateMuscleParameters Update the kinematic related parameters of the muscles
- Returns
- The force vector at origin and insertion
Implements BIORBD_NAMESPACE::internal_forces::muscles::Muscle.
Definition at line 86 of file IdealizedActuator.cpp.
◆ force() [3/3]
|
virtual |
Return the muscle force vector at origin and insertion.
- Parameters
-
model The joint model previously updated to the proper level Q The generalized coordinates emg The EMG data updateMuscleParameters Update the kinematic related parameters of the muscles
- Returns
- The force vector at origin and insertion
Implements BIORBD_NAMESPACE::internal_forces::muscles::Muscle.
Definition at line 96 of file IdealizedActuator.cpp.
◆ getForceFromActivation()
|
protectedvirtual |
Function allowing modification of the way the multiplication is done in computeForce(EMG).
- Parameters
-
emg The EMG data
- Returns
- The force from activation
Implements BIORBD_NAMESPACE::internal_forces::muscles::Muscle.
Definition at line 106 of file IdealizedActuator.cpp.
◆ setType()
|
protectedvirtual |
Set the type to Idealized_actuator.
Reimplemented from BIORBD_NAMESPACE::internal_forces::muscles::Muscle.
Definition at line 111 of file IdealizedActuator.cpp.
The documentation for this class was generated from the following files:
