Loading...
Searching...
No Matches
BIORBD_NAMESPACE::internal_forces::muscles::Muscle Class Referenceabstract
Base class of all muscle. More...
#include <Muscle.h>
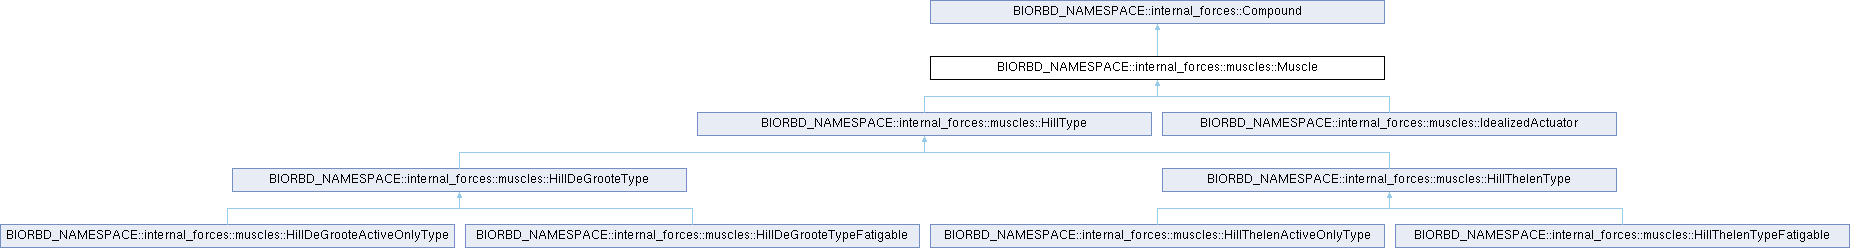
Inheritance diagram for BIORBD_NAMESPACE::internal_forces::muscles::Muscle:
Public Member Functions | |
| Muscle () | |
| Construct a muscle. | |
| Muscle (const utils::String &name, const internal_forces::muscles::MuscleGeometry &position, const Characteristics &characteristics) | |
| Construct a muscle. | |
| Muscle (const utils::String &name, const internal_forces::muscles::MuscleGeometry &position, const Characteristics &characteristics, const State &emg) | |
| Construct a muscle. | |
| Muscle (const utils::String &name, const internal_forces::muscles::MuscleGeometry &position, const Characteristics &characteristics, const internal_forces::PathModifiers &pathModifiers) | |
| Construct a muscle. | |
| Muscle (const utils::String &name, const internal_forces::muscles::MuscleGeometry &position, const Characteristics &characteristics, const internal_forces::PathModifiers &pathModifiers, const State &emg) | |
| Construct a muscle. | |
| Muscle (const Muscle &other) | |
| Construct a muscle from another muscle. | |
| Muscle (const std::shared_ptr< Muscle > other) | |
| Construct a muscle from another muscle. | |
| virtual | ~Muscle () |
| Destroy class properly. | |
| void | DeepCopy (const Muscle &other) |
| Deep copy of a muscle in new muscle. | |
| const utils::Scalar & | length (rigidbody::Joints &updatedModel, const rigidbody::GeneralizedCoordinates &Q, bool updateMuscleParameters=true) |
| Get the length of the muscle. | |
| const utils::Scalar & | musculoTendonLength (rigidbody::Joints &updatedModel, const rigidbody::GeneralizedCoordinates &Q, bool updateMuscleParameters=true) |
| Return the musculo tendon length. | |
| const utils::Scalar & | velocity (rigidbody::Joints &updatedModel, const rigidbody::GeneralizedCoordinates &Q, const rigidbody::GeneralizedVelocity &Qdot, bool updateMuscleParameters=true) |
| Return the velocity of the muscle. | |
| void | updateOrientations (rigidbody::Joints &updatedModel, const rigidbody::GeneralizedCoordinates &Q) |
| Update the position of the origin and insertion positions of the muscle. | |
| void | updateOrientations (rigidbody::Joints &updatedModel, const rigidbody::GeneralizedCoordinates &Q, const rigidbody::GeneralizedVelocity &Qdot) |
| Update the position of the origin and insertion nodes of the muscle. | |
| void | updateOrientations (std::vector< utils::Vector3d > &musclePointsInGlobal, utils::Matrix &jacoPointsInGlobal) |
| Update by hand the position of the origin and insertion nodes of the muscle. | |
| void | updateOrientations (std::vector< utils::Vector3d > &musclePointsInGlobal, utils::Matrix &jacoPointsInGlobal, const rigidbody::GeneralizedVelocity &Qdot) |
| Update by hand the position of the origin and insertion nodes of the muscle. | |
| void | setPosition (const internal_forces::muscles::MuscleGeometry &positions) |
| Set the position of all the points attached to the muscle (0 being the origin). | |
| const internal_forces::muscles::MuscleGeometry & | position () const |
| Return the position of all the points attached to the muscle (0 being the origin). | |
| void | setCharacteristics (const Characteristics &characteristics) |
| Set the muscle characteristics. | |
| Characteristics & | characteristics () const |
| Return the muscle characteristics. | |
| const std::vector< utils::Vector3d > & | musclesPointsInGlobal (rigidbody::Joints &updatedModel, const rigidbody::GeneralizedCoordinates &Q, bool updateMuscleParameters=true) |
| Return the muscle points in global reference frame. | |
| const std::vector< utils::Vector3d > & | musclesPointsInGlobal () const |
| Return the previously computed muscle points in global reference frame. | |
| void | setForceIsoMax (const utils::Scalar &forceMax) |
| Set the maximal isometric force. | |
| void | setState (const State &emg) |
| Set the dynamic state. | |
| const State & | state () const |
| Return the dynamic state. | |
| State & | state () |
| Return the dynamic state. | |
| const utils::Scalar & | activationDot (const State &state, bool alreadyNormalized=false) const |
| Return the activation time derivative. | |
| virtual const utils::Scalar & | force (const State &emg)=0 |
| Computes and returns the forces norm from the EMG. | |
| virtual const utils::Scalar & | force (rigidbody::Joints &updatedModel, const rigidbody::GeneralizedCoordinates &Q, const rigidbody::GeneralizedVelocity &Qdot, const State &emg, bool updateMuscleParameters=true)=0 |
| Return the computed force norm from EMG. | |
| virtual const utils::Scalar & | force (rigidbody::Joints &updatedModel, const rigidbody::GeneralizedCoordinates &Q, const State &emg, bool updateMuscleParameters=true)=0 |
| Return the computed force norm from EMG. | |
| MUSCLE_TYPE | type () const |
| Return the type of the muscle. | |
| Public Member Functions inherited from BIORBD_NAMESPACE::internal_forces::Compound | |
| Compound () | |
| Construct muscle compound. | |
| Compound (const utils::String &name) | |
| Construct compound. | |
| Compound (const utils::String &name, const internal_forces::PathModifiers &pathModifiers) | |
| Construct compound. | |
| Compound (const Compound &other) | |
| Construct compound from another muscle. | |
| Compound (const std::shared_ptr< Compound > other) | |
| Construct compound from another compound. | |
| virtual | ~Compound () |
| Destroy class properly. | |
| void | DeepCopy (const Compound &other) |
| Deep copy of a compound. | |
| void | setName (const utils::String &name) |
| Set the name of a muscle. | |
| const utils::String & | name () const |
| Return the name of the muscle. | |
| const internal_forces::PathModifiers & | pathModifier () |
| Return the path modifier. | |
| void | addPathObject (utils::Vector3d &wrap) |
| Add a path modifier object. | |
| virtual const utils::Scalar & | force () |
| Return the last computed muscle force norm. | |
Protected Member Functions | |
| virtual void | computeForce (const State &emg) |
| Computer the forces from a specific emg. | |
| virtual utils::Scalar | getForceFromActivation (const State &emg)=0 |
| Function allowing modification of the way the multiplication is done in computeForce(EMG). | |
| virtual void | setType () |
| Set the type of muscle. | |
Protected Attributes | |
| std::shared_ptr< MUSCLE_TYPE > | m_type |
| The type of the muscle. | |
| std::shared_ptr< internal_forces::muscles::MuscleGeometry > | m_position |
| The geometry (position of the nodes) of the muscle. | |
| std::shared_ptr< Characteristics > | m_characteristics |
| The muscle characteristics. | |
| std::shared_ptr< State > | m_state |
| The dynamic state. | |
| std::shared_ptr< utils::Scalar > | m_muscleLength |
| muscle tendon length | |
| Protected Attributes inherited from BIORBD_NAMESPACE::internal_forces::Compound | |
| std::shared_ptr< utils::String > | m_name |
| The name of the muscle. | |
| std::shared_ptr< internal_forces::PathModifiers > | m_pathChanger |
| The set of path modifiers. | |
| std::shared_ptr< utils::Scalar > | m_force |
| The last computed force. | |
Detailed Description
Constructor & Destructor Documentation
◆ Muscle() [1/7]
| internal_forces::muscles::Muscle::Muscle | ( | ) |
Construct a muscle.
Definition at line 19 of file Muscle.cpp.
◆ Muscle() [2/7]
| internal_forces::muscles::Muscle::Muscle | ( | const utils::String & | name, |
| const internal_forces::muscles::MuscleGeometry & | position, | ||
| const Characteristics & | characteristics ) |
Construct a muscle.
- Parameters
-
name Name of the muscle position Position of the origin/insertion characteristics Muscle characteristics from an initial state
Definition at line 31 of file Muscle.cpp.
◆ Muscle() [3/7]
| internal_forces::muscles::Muscle::Muscle | ( | const utils::String & | name, |
| const internal_forces::muscles::MuscleGeometry & | position, | ||
| const Characteristics & | characteristics, | ||
| const State & | emg ) |
Construct a muscle.
- Parameters
-
name Name of the muscle position Position of the origin/insertion characteristics Muscle characteristics from an initial state emg Dynamic state
Definition at line 46 of file Muscle.cpp.
◆ Muscle() [4/7]
| internal_forces::muscles::Muscle::Muscle | ( | const utils::String & | name, |
| const internal_forces::muscles::MuscleGeometry & | position, | ||
| const Characteristics & | characteristics, | ||
| const internal_forces::PathModifiers & | pathModifiers ) |
Construct a muscle.
- Parameters
-
name Name of the muscle position Position of the origin/insertion characteristics Muscle characteristics from an initial state pathModifiers The path modifiers
Definition at line 64 of file Muscle.cpp.
◆ Muscle() [5/7]
| internal_forces::muscles::Muscle::Muscle | ( | const utils::String & | name, |
| const internal_forces::muscles::MuscleGeometry & | position, | ||
| const Characteristics & | characteristics, | ||
| const internal_forces::PathModifiers & | pathModifiers, | ||
| const State & | emg ) |
Construct a muscle.
- Parameters
-
name Name of the muscle position Position of the origin/insertion characteristics Muscle characteristics from an initial state pathModifiers The path modifier emg The dynamic state
Definition at line 95 of file Muscle.cpp.
◆ Muscle() [6/7]
| internal_forces::muscles::Muscle::Muscle | ( | const Muscle & | other | ) |
Construct a muscle from another muscle.
- Parameters
-
other The other muscle
Definition at line 80 of file Muscle.cpp.
◆ Muscle() [7/7]
| internal_forces::muscles::Muscle::Muscle | ( | const std::shared_ptr< Muscle > | other | ) |
Construct a muscle from another muscle.
- Parameters
-
other The other muscle
Definition at line 88 of file Muscle.cpp.
◆ ~Muscle()
|
virtual |
Destroy class properly.
Definition at line 116 of file Muscle.cpp.
Member Function Documentation
◆ activationDot()
| const utils::Scalar & internal_forces::muscles::Muscle::activationDot | ( | const State & | state, |
| bool | alreadyNormalized = false ) const |
Return the activation time derivative.
- Parameters
-
state The dynamic state alreadyNormalized If the emg is already normalized
- Returns
- The activation time derivative
Definition at line 209 of file Muscle.cpp.
◆ characteristics()
| internal_forces::muscles::Characteristics & internal_forces::muscles::Muscle::characteristics | ( | ) | const |
Return the muscle characteristics.
- Returns
- The muscle characteristics
Definition at line 254 of file Muscle.cpp.
◆ computeForce()
|
protectedvirtual |
Computer the forces from a specific emg.
- Parameters
-
emg EMG data
Definition at line 222 of file Muscle.cpp.
◆ DeepCopy()
| void internal_forces::muscles::Muscle::DeepCopy | ( | const Muscle & | other | ) |
Deep copy of a muscle in new muscle.
- Parameters
-
other The muscle to copy
Definition at line 120 of file Muscle.cpp.
◆ force() [1/3]
|
pure virtual |
Computes and returns the forces norm from the EMG.
- Parameters
-
emg EMG data
- Returns
- The computed forces from the EMG
Implemented in BIORBD_NAMESPACE::internal_forces::muscles::HillType, and BIORBD_NAMESPACE::internal_forces::muscles::IdealizedActuator.
◆ force() [2/3]
|
pure virtual |
Return the computed force norm from EMG.
- Parameters
-
updatedModel The joint model previously updated to the proper level Q The generalized coordinates of the model Qdot The generalized velocities of the model emg EMG data updateMuscleParameters Update the kinematic related parameters of the muscles
- Returns
- The computed force from EMG
Implemented in BIORBD_NAMESPACE::internal_forces::muscles::HillType, and BIORBD_NAMESPACE::internal_forces::muscles::IdealizedActuator.
◆ force() [3/3]
|
pure virtual |
Return the computed force norm from EMG.
- Parameters
-
updatedModel The joint model previously updated to the proper level Q The generalized coordinates of the model emg EMG data updateMuscleParameters Update the kinematic related parameters of the muscles
- Returns
- The computed force from EMG
Implemented in BIORBD_NAMESPACE::internal_forces::muscles::HillType, and BIORBD_NAMESPACE::internal_forces::muscles::IdealizedActuator.
◆ getForceFromActivation()
|
protectedpure virtual |
Function allowing modification of the way the multiplication is done in computeForce(EMG).
- Parameters
-
emg The EMG data
- Returns
- The force from activation
Implemented in BIORBD_NAMESPACE::internal_forces::muscles::HillType, and BIORBD_NAMESPACE::internal_forces::muscles::IdealizedActuator.
◆ length()
| const utils::Scalar & internal_forces::muscles::Muscle::length | ( | rigidbody::Joints & | updatedModel, |
| const rigidbody::GeneralizedCoordinates & | Q, | ||
| bool | updateMuscleParameters = true ) |
Get the length of the muscle.
- Parameters
-
updatedModel The joint model previously updated to the proper level Q The generalized coordinates updateMuscleParameters Update the kinematic related parameters of the muscles
- Returns
- The length of the muscle
Definition at line 178 of file Muscle.cpp.
◆ musclesPointsInGlobal() [1/2]
| const std::vector< utils::Vector3d > & internal_forces::muscles::Muscle::musclesPointsInGlobal | ( | ) | const |
Return the previously computed muscle points in global reference frame.
- Returns
- The muscle points in global reference frame
Definition at line 239 of file Muscle.cpp.
◆ musclesPointsInGlobal() [2/2]
| const std::vector< utils::Vector3d > & internal_forces::muscles::Muscle::musclesPointsInGlobal | ( | rigidbody::Joints & | updatedModel, |
| const rigidbody::GeneralizedCoordinates & | Q, | ||
| bool | updateMuscleParameters = true ) |
Return the muscle points in global reference frame.
- Parameters
-
updatedModel The updated joint model (The user must ensure that the model is updated to the proper level) Q The generalized coordinates updateMuscleParameters Update the kinematic related parameters of the muscles
- Returns
- The muscle points in global reference frame
Definition at line 228 of file Muscle.cpp.
◆ musculoTendonLength()
| const utils::Scalar & internal_forces::muscles::Muscle::musculoTendonLength | ( | rigidbody::Joints & | updatedModel, |
| const rigidbody::GeneralizedCoordinates & | Q, | ||
| bool | updateMuscleParameters = true ) |
Return the musculo tendon length.
- Parameters
-
updatedModel The joint model previously updated to the proper level Q The generalized coordinates updateMuscleParameters Update the kinematic related parameters of the muscles
- Returns
- The musculo tendon length
Definition at line 188 of file Muscle.cpp.
◆ position()
| const internal_forces::muscles::MuscleGeometry & internal_forces::muscles::Muscle::position | ( | ) | const |
Return the position of all the points attached to the muscle (0 being the origin).
- Returns
- The positions
Definition at line 174 of file Muscle.cpp.
◆ setCharacteristics()
| void internal_forces::muscles::Muscle::setCharacteristics | ( | const Characteristics & | characteristics | ) |
Set the muscle characteristics.
- Parameters
-
characteristics New value of the muscle characteristics
Definition at line 248 of file Muscle.cpp.
◆ setForceIsoMax()
| void internal_forces::muscles::Muscle::setForceIsoMax | ( | const utils::Scalar & | forceMax | ) |
Set the maximal isometric force.
- Parameters
-
forceMax The force to set
Definition at line 243 of file Muscle.cpp.
◆ setPosition()
| void internal_forces::muscles::Muscle::setPosition | ( | const internal_forces::muscles::MuscleGeometry & | positions | ) |
Set the position of all the points attached to the muscle (0 being the origin).
- Parameters
-
positions New value of the position
Definition at line 169 of file Muscle.cpp.
◆ setState()
| void internal_forces::muscles::Muscle::setState | ( | const State & | emg | ) |
Set the dynamic state.
- Parameters
-
emg The dynamic state value
Definition at line 259 of file Muscle.cpp.
◆ setType()
|
protectedvirtual |
Set the type of muscle.
Reimplemented in BIORBD_NAMESPACE::internal_forces::muscles::HillDeGrooteActiveOnlyType, BIORBD_NAMESPACE::internal_forces::muscles::HillDeGrooteType, BIORBD_NAMESPACE::internal_forces::muscles::HillDeGrooteTypeFatigable, BIORBD_NAMESPACE::internal_forces::muscles::HillThelenActiveOnlyType, BIORBD_NAMESPACE::internal_forces::muscles::HillThelenType, BIORBD_NAMESPACE::internal_forces::muscles::HillThelenTypeFatigable, BIORBD_NAMESPACE::internal_forces::muscles::HillType, and BIORBD_NAMESPACE::internal_forces::muscles::IdealizedActuator.
Definition at line 134 of file Muscle.cpp.
◆ state() [1/2]
| internal_forces::muscles::State & internal_forces::muscles::Muscle::state | ( | ) |
◆ state() [2/2]
| const internal_forces::muscles::State & internal_forces::muscles::Muscle::state | ( | ) | const |
◆ type()
| internal_forces::muscles::MUSCLE_TYPE internal_forces::muscles::Muscle::type | ( | ) | const |
Return the type of the muscle.
- Returns
- The type of the muscle
Definition at line 129 of file Muscle.cpp.
◆ updateOrientations() [1/4]
| void internal_forces::muscles::Muscle::updateOrientations | ( | rigidbody::Joints & | updatedModel, |
| const rigidbody::GeneralizedCoordinates & | Q ) |
Update the position of the origin and insertion positions of the muscle.
- Parameters
-
updatedModel The joint model previously updated to the proper level Q The generalized coordinates
Definition at line 138 of file Muscle.cpp.
◆ updateOrientations() [2/4]
| void internal_forces::muscles::Muscle::updateOrientations | ( | rigidbody::Joints & | updatedModel, |
| const rigidbody::GeneralizedCoordinates & | Q, | ||
| const rigidbody::GeneralizedVelocity & | Qdot ) |
Update the position of the origin and insertion nodes of the muscle.
- Parameters
-
updatedModel The joint model previously updated to the proper level Q The generalized coordinates Qdot The generalized velocities
Definition at line 145 of file Muscle.cpp.
◆ updateOrientations() [3/4]
| void internal_forces::muscles::Muscle::updateOrientations | ( | std::vector< utils::Vector3d > & | musclePointsInGlobal, |
| utils::Matrix & | jacoPointsInGlobal ) |
Update by hand the position of the origin and insertion nodes of the muscle.
- Parameters
-
musclePointsInGlobal The muscle points jacoPointsInGlobal The jacobian matrix
Definition at line 153 of file Muscle.cpp.
◆ updateOrientations() [4/4]
| void internal_forces::muscles::Muscle::updateOrientations | ( | std::vector< utils::Vector3d > & | musclePointsInGlobal, |
| utils::Matrix & | jacoPointsInGlobal, | ||
| const rigidbody::GeneralizedVelocity & | Qdot ) |
Update by hand the position of the origin and insertion nodes of the muscle.
- Parameters
-
musclePointsInGlobal The muscle points jacoPointsInGlobal The Jacobian matrix Qdot The genelized velocities
Definition at line 160 of file Muscle.cpp.
◆ velocity()
| const utils::Scalar & internal_forces::muscles::Muscle::velocity | ( | rigidbody::Joints & | updatedModel, |
| const rigidbody::GeneralizedCoordinates & | Q, | ||
| const rigidbody::GeneralizedVelocity & | Qdot, | ||
| bool | updateMuscleParameters = true ) |
Return the velocity of the muscle.
- Parameters
-
updatedModel The joint model previously updated to the proper level Q The generalized coordinates Qdot The generalized velocities updateMuscleParameters Update the kinematic related parameters of the muscles
- Returns
- The velocity of the muscle
Definition at line 198 of file Muscle.cpp.
Member Data Documentation
◆ m_characteristics
|
protected |
◆ m_muscleLength
|
protected |
◆ m_position
|
protected |
◆ m_state
|
protected |
◆ m_type
|
protected |
The documentation for this class was generated from the following files:
