Loading...
Searching...
No Matches
BIORBD_NAMESPACE::rigidbody::Contacts Class Reference
#include <Contacts.h>
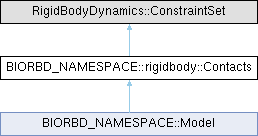
Inheritance diagram for BIORBD_NAMESPACE::rigidbody::Contacts:
Public Member Functions | |
| Contacts () | |
| Construct contacts. | |
| Contacts | DeepCopy () const |
| Deep copy of contacts. | |
| void | DeepCopy (const Contacts &other) |
| Deep copy of contacts. | |
| size_t | AddConstraint (size_t bodyId, const utils::Vector3d &bodyPoint, const utils::Vector3d &worldNormal, const utils::String &name, const utils::String &parentName) |
| Add a constraint to the constraint set. | |
| size_t | AddConstraint (size_t bodyId, const utils::Vector3d &bodyPoint, const utils::String &axis, const utils::String &name, const utils::String &parentName) |
| Add a constraint to the constraint set. | |
| size_t | AddLoopConstraint (size_t body_id_predecessor, size_t body_id_successor, const utils::RotoTrans &X_predecessor, const utils::RotoTrans &X_successor, const utils::SpatialVector &axis, const utils::String &name, bool enableStabilization=false, double stabilizationParam=0.1) |
| Add a loop constraint to the constraint set. | |
| std::vector< utils::SpatialVector > | calcLoopConstraintForces (const rigidbody::GeneralizedCoordinates &Q, const rigidbody::GeneralizedVelocity &Qdot, const rigidbody::GeneralizedTorque &Tau) |
| compute the forces generated from loop constraints | |
| std::vector< utils::SpatialVector > | calcLoopConstraintForces (const rigidbody::GeneralizedCoordinates &Q, const rigidbody::GeneralizedVelocity &Qdot, const rigidbody::GeneralizedTorque &Tau, rigidbody::ExternalForceSet &externalForces) |
| compute the forces generated from loop constraints | |
| virtual | ~Contacts () |
| Destroy the class properly. | |
| Contacts & | getConstraints () |
| Get constraints. | |
| bool | hasContacts () const |
| Check if there are contacts. | |
| bool | hasLoopConstraints () const |
| Check if there are loop constraints. | |
| size_t | nbContacts () const |
| Return the number of contacts. | |
| size_t | nbLoopConstraints () const |
| Return the number of loop constraints. | |
| std::vector< utils::String > | contactNames () |
| Return the name of the all contacts. | |
| utils::String | contactName (size_t i) |
| Return the name of the contact of a specified axis. | |
| size_t | contactRbdlId (const utils::String &name) |
| Return the index of the contact corresponding to the given name. | |
| std::vector< utils::Vector3d > | constraintsInGlobal (const GeneralizedCoordinates &Q, bool updateKin) |
| Return the constraints position in the global reference. | |
| utils::Vector | getForce () const |
| Return the force acting on the constraint. | |
| int | contactSegmentBiorbdId (int idx) const |
| Return the segment idx of the contact in biorbd formalism. | |
| std::vector< size_t > | segmentRigidContactIdx (int segment_idx) const |
| Return the index of rigid contacts for a specified segment index. | |
| int | nbRigidContacts () const |
| Returns the number of rigid contacts (ignoring the loop constraints). | |
| const std::vector< NodeSegment > & | rigidContacts () const |
| Returns all the rigid contacts as declared in the model. | |
| const NodeSegment & | rigidContact (size_t idx) const |
| Returns the rigid contact idx as declared in the model. | |
| utils::Vector3d | rigidContact (const GeneralizedCoordinates &Q, size_t idx, bool updateKin) |
| Return the rigidContact position in the global reference. | |
| std::vector< utils::Vector3d > | rigidContacts (const GeneralizedCoordinates &Q, bool updateKin) |
| Return all the rigidContacts position in the global reference. | |
| utils::Vector3d | rigidContactVelocity (const rigidbody::GeneralizedCoordinates &Q, const rigidbody::GeneralizedVelocity &Qdot, size_t idx, bool updateKin=true) |
| Return the velocity of the chosen contact. | |
| std::vector< utils::Vector3d > | rigidContactsVelocity (const rigidbody::GeneralizedCoordinates &Q, const rigidbody::GeneralizedVelocity &Qdot, bool updateKin=true) |
| Return the velocities of all the contacts. | |
| utils::Vector3d | rigidContactAcceleration (const rigidbody::GeneralizedCoordinates &Q, const rigidbody::GeneralizedVelocity &Qdot, const rigidbody::GeneralizedAcceleration &dQdot, size_t idx, bool updateKin=true) |
| Return the acceleration of the chosen contact. | |
| std::vector< utils::Vector3d > | rigidContactsAcceleration (const rigidbody::GeneralizedCoordinates &Q, const rigidbody::GeneralizedVelocity &Qdot, const rigidbody::GeneralizedAcceleration &dQdot, bool updateKin=true) |
| Return the acceleration of all the contacts. | |
| utils::Matrix | rigidContactJacobian (rigidbody::Joints &updatedModel, const rigidbody::GeneralizedCoordinates &Q, size_t idx) |
| Compute the Jacobian of a single rigid contact. | |
| utils::Matrix | rigidContactJacobian (const rigidbody::GeneralizedCoordinates &Q, size_t idx, bool updateKin=true) |
| Compute the Jacobian of a single rigid contact. | |
| std::vector< utils::Matrix > | rigidContactsJacobian (rigidbody::Joints &updatedModel, const rigidbody::GeneralizedCoordinates &Q) |
| Compute the Jacobians of all rigid contacts. | |
| std::vector< utils::Matrix > | rigidContactsJacobian (const rigidbody::GeneralizedCoordinates &Q, bool updateKin=true) |
| Compute the Jacobians of all rigid contacts. | |
Protected Member Functions | |
| utils::String | swapAxes (const utils::String &axesToSwap) const |
| Swap the status of the axes provided, that is adding x, y or z if it is not there and remove them otherwise. This effectively transform an allowed axes set to a axes to remove set, or vice versa. | |
Static Protected Member Functions | |
| static utils::Matrix | projectContactJacobian (const utils::Matrix &J, const rigidbody::NodeSegment &contact) |
| Project a 3D point Jacobian onto active contact axes. | |
Protected Attributes | |
| std::shared_ptr< size_t > | m_nbreConstraint |
| Number of constraints. | |
| std::shared_ptr< bool > | m_isBinded |
| If the model is ready. | |
| std::shared_ptr< std::vector< rigidbody::NodeSegment > > | m_rigidContacts |
| std::shared_ptr< size_t > | m_nbLoopConstraint |
| Number of constraints. | |
Detailed Description
Class Contacts.
Definition at line 36 of file Contacts.h.
Constructor & Destructor Documentation
◆ Contacts()
| rigidbody::Contacts::Contacts | ( | ) |
Construct contacts.
Definition at line 25 of file Contacts.cpp.
◆ ~Contacts()
|
virtual |
Destroy the class properly.
Definition at line 225 of file Contacts.cpp.
Member Function Documentation
◆ AddConstraint() [1/2]
| size_t rigidbody::Contacts::AddConstraint | ( | size_t | bodyId, |
| const utils::Vector3d & | bodyPoint, | ||
| const utils::String & | axis, | ||
| const utils::String & | name, | ||
| const utils::String & | parentName ) |
Add a constraint to the constraint set.
- Parameters
-
bodyId The body which is affected directly by the constraint bodyPoint The point that is constrained relative to the contact body axis The axis along which the constraint acts name A human readable name parentName A human readable name of the parent (should correspond to the body_id)
- Returns
- The index of the new constraint
Definition at line 93 of file Contacts.cpp.
◆ AddConstraint() [2/2]
| size_t rigidbody::Contacts::AddConstraint | ( | size_t | bodyId, |
| const utils::Vector3d & | bodyPoint, | ||
| const utils::Vector3d & | worldNormal, | ||
| const utils::String & | name, | ||
| const utils::String & | parentName ) |
Add a constraint to the constraint set.
- Parameters
-
bodyId The body which is affected directly by the constraint bodyPoint The point that is constrained relative to the contact body worldNormal The normal along the constraint acts (in base coordinates) name A human readable name parentName A human readable name of the parent (should correspond to the body_id)
- Returns
- The index of the new constraint
Definition at line 46 of file Contacts.cpp.
◆ AddLoopConstraint()
| size_t rigidbody::Contacts::AddLoopConstraint | ( | size_t | body_id_predecessor, |
| size_t | body_id_successor, | ||
| const utils::RotoTrans & | X_predecessor, | ||
| const utils::RotoTrans & | X_successor, | ||
| const utils::SpatialVector & | axis, | ||
| const utils::String & | name, | ||
| bool | enableStabilization = false, | ||
| double | stabilizationParam = 0.1 ) |
Add a loop constraint to the constraint set.
- Parameters
-
body_id_predecessor The identifier of the predecessor body body_id_successor The identifier of the successor body X_predecessor A spatial transform localizing the constrained frames on the predecessor body, expressed with respect to the predecessor body frame X_successor A spatial transform localizing the constrained frames on the successor body, expressed with respect to the successor body frame axis A spatial vector indicating the axis along which the constraint acts name A human readable name enableStabilization Whether stabilization should be enabled or not stabilizationParam The value used for stabilization
- Returns
- The index of the new constraint
Definition at line 139 of file Contacts.cpp.
◆ calcLoopConstraintForces() [1/2]
| std::vector< utils::SpatialVector > rigidbody::Contacts::calcLoopConstraintForces | ( | const rigidbody::GeneralizedCoordinates & | Q, |
| const rigidbody::GeneralizedVelocity & | Qdot, | ||
| const rigidbody::GeneralizedTorque & | Tau ) |
compute the forces generated from loop constraints
- Parameters
-
Q The generalized coordinates Qdot The generalized velocities Tau The generalized torques
- Returns
- The forces generated by the loop closure at the predecessor in the global frame
Definition at line 163 of file Contacts.cpp.
◆ calcLoopConstraintForces() [2/2]
| std::vector< utils::SpatialVector > rigidbody::Contacts::calcLoopConstraintForces | ( | const rigidbody::GeneralizedCoordinates & | Q, |
| const rigidbody::GeneralizedVelocity & | Qdot, | ||
| const rigidbody::GeneralizedTorque & | Tau, | ||
| rigidbody::ExternalForceSet & | externalForces ) |
compute the forces generated from loop constraints
- Parameters
-
Q The generalized coordinates Qdot The generalized velocities Tau The generalized torques externalForces the external forces
- Returns
- The forces generated by the loop closure at the predecessor in the global frame
Definition at line 171 of file Contacts.cpp.
◆ constraintsInGlobal()
| std::vector< utils::Vector3d > rigidbody::Contacts::constraintsInGlobal | ( | const GeneralizedCoordinates & | Q, |
| bool | updateKin ) |
Return the constraints position in the global reference.
- Parameters
-
Q The generalized coordinates of the joints updateKin Whether the kinematics of the model should be updated from Q
- Returns
- The constraints positions in the global reference
Definition at line 284 of file Contacts.cpp.
◆ contactName()
| utils::String rigidbody::Contacts::contactName | ( | size_t | i | ) |
Return the name of the contact of a specified axis.
- Parameters
-
i The axis
- Returns
- The name of the contact of a specified axis
Definition at line 267 of file Contacts.cpp.
◆ contactNames()
| std::vector< utils::String > rigidbody::Contacts::contactNames | ( | ) |
Return the name of the all contacts.
- Returns
- The name of the contacts
Definition at line 259 of file Contacts.cpp.
◆ contactRbdlId()
| size_t BIORBD_NAMESPACE::rigidbody::Contacts::contactRbdlId | ( | const utils::String & | name | ) |
Return the index of the contact corresponding to the given name.
- Parameters
-
name The name of the contact
- Returns
- The index of the contact
- Exceptions
-
std::runtime_error if the contact does not exist
Definition at line 273 of file Contacts.cpp.
◆ contactSegmentBiorbdId()
| int rigidbody::Contacts::contactSegmentBiorbdId | ( | int | idx | ) | const |
Return the segment idx of the contact in biorbd formalism.
- Parameters
-
idx The index of the contact
- Returns
- segment idx of the contact in biorbd formalism
Definition at line 497 of file Contacts.cpp.
◆ DeepCopy() [1/2]
| rigidbody::Contacts rigidbody::Contacts::DeepCopy | ( | ) | const |
◆ DeepCopy() [2/2]
| void rigidbody::Contacts::DeepCopy | ( | const Contacts & | other | ) |
Deep copy of contacts.
- Parameters
-
other The contacts to copy
Definition at line 38 of file Contacts.cpp.
◆ getConstraints()
| rigidbody::Contacts & rigidbody::Contacts::getConstraints | ( | ) |
◆ getForce()
| utils::Vector rigidbody::Contacts::getForce | ( | ) | const |
Return the force acting on the constraint.
- Returns
- The force acting on the constraint
Definition at line 478 of file Contacts.cpp.
◆ hasContacts()
| bool rigidbody::Contacts::hasContacts | ( | ) | const |
Check if there are contacts.
- Returns
- The presence of contacts
Definition at line 237 of file Contacts.cpp.
◆ hasLoopConstraints()
| bool rigidbody::Contacts::hasLoopConstraints | ( | ) | const |
Check if there are loop constraints.
- Returns
- The presence of loop constraints
Definition at line 245 of file Contacts.cpp.
◆ nbContacts()
| size_t rigidbody::Contacts::nbContacts | ( | ) | const |
Return the number of contacts.
- Returns
- The number of contacts
Definition at line 253 of file Contacts.cpp.
◆ nbLoopConstraints()
| size_t rigidbody::Contacts::nbLoopConstraints | ( | ) | const |
Return the number of loop constraints.
- Returns
- The number of loop constraints
Definition at line 255 of file Contacts.cpp.
◆ nbRigidContacts()
| int rigidbody::Contacts::nbRigidContacts | ( | ) | const |
Returns the number of rigid contacts (ignoring the loop constraints).
- Returns
- The number of rigid contacts (ignoring the loop constraints)
Definition at line 493 of file Contacts.cpp.
◆ projectContactJacobian()
|
staticprotected |
Project a 3D point Jacobian onto active contact axes.
- Parameters
-
J The full 3xN Jacobian of the contact point contact The rigid contact definition (provides active axes)
- Returns
- The reduced Jacobian containing only active axes
Definition at line 400 of file Contacts.cpp.
◆ rigidContact() [1/2]
| utils::Vector3d rigidbody::Contacts::rigidContact | ( | const GeneralizedCoordinates & | Q, |
| size_t | idx, | ||
| bool | updateKin ) |
Return the rigidContact position in the global reference.
- Parameters
-
Q The generalized coordinates of the joints idx The index of the contact updateKin Whether the kinematics of the model should be updated from Q
- Returns
- The rigidContact position in the global reference
Definition at line 305 of file Contacts.cpp.
◆ rigidContact() [2/2]
| const rigidbody::NodeSegment & rigidbody::Contacts::rigidContact | ( | size_t | idx | ) | const |
Returns the rigid contact idx as declared in the model.
- Parameters
-
idx The index of the contact
- Returns
- All the rigid contacts as declared in the model
Definition at line 487 of file Contacts.cpp.
◆ rigidContactAcceleration()
| utils::Vector3d rigidbody::Contacts::rigidContactAcceleration | ( | const rigidbody::GeneralizedCoordinates & | Q, |
| const rigidbody::GeneralizedVelocity & | Qdot, | ||
| const rigidbody::GeneralizedAcceleration & | dQdot, | ||
| size_t | idx, | ||
| bool | updateKin = true ) |
Return the acceleration of the chosen contact.
- Parameters
-
Q The generalized coordinates Qdot The generalized velocities dQdot The generalized accelerations idx The index of the contact updateKin If the model should be updated
- Returns
- The acceleration of the chosen contact
Definition at line 366 of file Contacts.cpp.
◆ rigidContactJacobian() [1/2]
| utils::Matrix rigidbody::Contacts::rigidContactJacobian | ( | const rigidbody::GeneralizedCoordinates & | Q, |
| size_t | idx, | ||
| bool | updateKin = true ) |
Compute the Jacobian of a single rigid contact.
- Parameters
-
Q The generalized coordinates idx Index of the rigid contact updateKin If true, update kinematics before computation
- Returns
- The Jacobian of the selected contact (projected onto active axes)
Definition at line 434 of file Contacts.cpp.
◆ rigidContactJacobian() [2/2]
| utils::Matrix rigidbody::Contacts::rigidContactJacobian | ( | rigidbody::Joints & | updatedModel, |
| const rigidbody::GeneralizedCoordinates & | Q, | ||
| size_t | idx ) |
Compute the Jacobian of a single rigid contact.
- Parameters
-
updatedModel The kinematic model with updated state Q The generalized coordinates idx Index of the rigid contact
- Returns
- The Jacobian of the selected contact (projected onto active axes)
Definition at line 422 of file Contacts.cpp.
◆ rigidContacts() [1/2]
| const std::vector< rigidbody::NodeSegment > & rigidbody::Contacts::rigidContacts | ( | ) | const |
Returns all the rigid contacts as declared in the model.
- Returns
- All the rigid contacts as declared in the model
Definition at line 482 of file Contacts.cpp.
◆ rigidContacts() [2/2]
| std::vector< utils::Vector3d > rigidbody::Contacts::rigidContacts | ( | const GeneralizedCoordinates & | Q, |
| bool | updateKin ) |
Return all the rigidContacts position in the global reference.
- Parameters
-
Q The generalized coordinates of the joints updateKin Whether the kinematics of the model should be updated from Q
- Returns
- All the rigidContacts positions in the global reference
Definition at line 317 of file Contacts.cpp.
◆ rigidContactsAcceleration()
| std::vector< utils::Vector3d > rigidbody::Contacts::rigidContactsAcceleration | ( | const rigidbody::GeneralizedCoordinates & | Q, |
| const rigidbody::GeneralizedVelocity & | Qdot, | ||
| const rigidbody::GeneralizedAcceleration & | dQdot, | ||
| bool | updateKin = true ) |
Return the acceleration of all the contacts.
- Parameters
-
Q The generalized coordinates Qdot The generalized velocities dQdot The generalized accelerations updateKin If the model should be updated
- Returns
- The acceleration of all the contacts
Definition at line 381 of file Contacts.cpp.
◆ rigidContactsJacobian() [1/2]
| std::vector< utils::Matrix > rigidbody::Contacts::rigidContactsJacobian | ( | const rigidbody::GeneralizedCoordinates & | Q, |
| bool | updateKin = true ) |
Compute the Jacobians of all rigid contacts.
- Parameters
-
Q The generalized coordinates updateKin If true, update kinematics before computation
- Returns
- Vector of Jacobians for all rigid contacts (projected onto active axes)
Definition at line 450 of file Contacts.cpp.
◆ rigidContactsJacobian() [2/2]
| std::vector< utils::Matrix > rigidbody::Contacts::rigidContactsJacobian | ( | rigidbody::Joints & | updatedModel, |
| const rigidbody::GeneralizedCoordinates & | Q ) |
Compute the Jacobians of all rigid contacts.
- Parameters
-
updatedModel The kinematic model with updated state Q The generalized coordinates
- Returns
- Vector of Jacobians for all rigid contacts (projected onto active axes)
Definition at line 465 of file Contacts.cpp.
◆ rigidContactsVelocity()
| std::vector< utils::Vector3d > rigidbody::Contacts::rigidContactsVelocity | ( | const rigidbody::GeneralizedCoordinates & | Q, |
| const rigidbody::GeneralizedVelocity & | Qdot, | ||
| bool | updateKin = true ) |
Return the velocities of all the contacts.
- Parameters
-
Q The generalized coordinates Qdot The generalized velocities updateKin If the model should be updated
- Returns
- The velocities of all the contacts
Definition at line 349 of file Contacts.cpp.
◆ rigidContactVelocity()
| utils::Vector3d rigidbody::Contacts::rigidContactVelocity | ( | const rigidbody::GeneralizedCoordinates & | Q, |
| const rigidbody::GeneralizedVelocity & | Qdot, | ||
| size_t | idx, | ||
| bool | updateKin = true ) |
Return the velocity of the chosen contact.
- Parameters
-
Q The generalized coordinates Qdot The generalized velocities idx The index of the contact updateKin If the model should be updated
- Returns
- The velocity of the chosen contact
Definition at line 336 of file Contacts.cpp.
◆ segmentRigidContactIdx()
| std::vector< size_t > rigidbody::Contacts::segmentRigidContactIdx | ( | int | segment_idx | ) | const |
Return the index of rigid contacts for a specified segment index.
- Parameters
-
segment_idx The index of the segment
- Returns
- the index of rigid contacts for the specified segment idx
Definition at line 510 of file Contacts.cpp.
◆ swapAxes()
|
protected |
Swap the status of the axes provided, that is adding x, y or z if it is not there and remove them otherwise. This effectively transform an allowed axes set to a axes to remove set, or vice versa.
- Parameters
-
axesToSwap a vector of up to three values (being "x", "y" or "z")
- Returns
- The swapped axes
Definition at line 525 of file Contacts.cpp.
Member Data Documentation
◆ m_isBinded
|
protected |
If the model is ready.
Definition at line 391 of file Contacts.h.
◆ m_nbLoopConstraint
|
protected |
Number of constraints.
Definition at line 395 of file Contacts.h.
◆ m_nbreConstraint
|
protected |
Number of constraints.
Definition at line 390 of file Contacts.h.
◆ m_rigidContacts
|
protected |
The rigid contacts declared in the model (copy of RBDL information)
Definition at line 393 of file Contacts.h.
The documentation for this class was generated from the following files:
