Loading...
Searching...
No Matches
BIORBD_NAMESPACE::rigidbody::KalmanRecons Class Referenceabstract
Class Kinematic reconstruction algorithm using an Extended Kalman Filter. More...
#include <KalmanRecons.h>
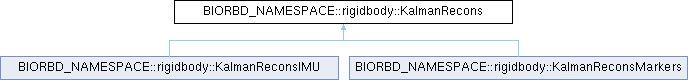
Inheritance diagram for BIORBD_NAMESPACE::rigidbody::KalmanRecons:
Public Member Functions | |
| KalmanRecons () | |
| Kalman reconstruction. | |
| KalmanRecons (Model &model, size_t nbMeasure, KalmanParam params=KalmanParam()) | |
| Kalman reconstruction. | |
| virtual | ~KalmanRecons () |
| Destroy class properly. | |
| void | DeepCopy (const KalmanRecons &other) |
| Deep copy of Kalman reconstruction. | |
| void | getState (GeneralizedCoordinates *Q=nullptr, GeneralizedVelocity *Qdot=nullptr, GeneralizedAcceleration *Qddot=nullptr) |
| Get the state (Q, Qdot, Qddot). | |
| void | setInitState (const GeneralizedCoordinates *Q=nullptr, const GeneralizedVelocity *Qdot=nullptr, const GeneralizedAcceleration *Qddot=nullptr) |
| Set the initial guess of the reconstruction. | |
| virtual void | reconstructFrame ()=0 |
| Proceed to one iteration of the Kalman filter. | |
Protected Member Functions | |
| virtual void | initialize () |
| Initialization of the filter. | |
| utils::Matrix | evolutionMatrix (const size_t m, size_t n, double Te) |
| Create the evolution matrix. | |
| utils::Matrix | processNoiseMatrix (const size_t nbQ, double Te) |
| Process the noise matrix. | |
| utils::Matrix | measurementNoiseMatrix (const size_t nbT, double val) |
| Matrix of the noise on the measurements. | |
| utils::Matrix | initCovariance (const size_t nbQ, double val) |
| Returns a initialized covianriance matrix. | |
| GeneralizedCoordinates | initState (const size_t nbQ) |
| Initialize the states. | |
| void | iteration (utils::Vector measure, const utils::Vector &projectedMeasure, const utils::Matrix &Hessian, const std::vector< size_t > &occlusion=std::vector< size_t >()) |
| Compute an iteration of the Kalman filter. | |
| virtual void | manageOcclusionDuringIteration (utils::Matrix &InvTp, utils::Vector &measure, const std::vector< size_t > &occlusion) |
| Manage the occlusion during the iteration. | |
Protected Attributes | |
| std::shared_ptr< KalmanParam > | m_params |
| The parameters of the Kalman filter. | |
| std::shared_ptr< double > | m_Te |
| Inherent parameter to the frequency. | |
| std::shared_ptr< size_t > | m_nbDof |
| Number of states. | |
| std::shared_ptr< size_t > | m_nMeasure |
| Number of measurements. | |
| std::shared_ptr< utils::Vector > | m_xp |
| State vector. | |
| std::shared_ptr< utils::Matrix > | m_A |
| Evolution matrix. | |
| std::shared_ptr< utils::Matrix > | m_Q |
| Noise matrix. | |
| std::shared_ptr< utils::Matrix > | m_R |
| Matrix of the noise on the measurements. | |
| std::shared_ptr< utils::Matrix > | m_Pp |
| Covariance matrix. | |
Detailed Description
Class Kinematic reconstruction algorithm using an Extended Kalman Filter.
Definition at line 66 of file KalmanRecons.h.
Constructor & Destructor Documentation
◆ KalmanRecons() [1/2]
| rigidbody::KalmanRecons::KalmanRecons | ( | ) |
Kalman reconstruction.
Definition at line 13 of file KalmanRecons.cpp.
◆ KalmanRecons() [2/2]
| rigidbody::KalmanRecons::KalmanRecons | ( | Model & | model, |
| size_t | nbMeasure, | ||
| KalmanParam | params = KalmanParam() ) |
Kalman reconstruction.
- Parameters
-
model The joint model nbMeasure The number of measurements params The Kalman filter parameters
Definition at line 24 of file KalmanRecons.cpp.
◆ ~KalmanRecons()
|
virtual |
Destroy class properly.
Definition at line 38 of file KalmanRecons.cpp.
Member Function Documentation
◆ DeepCopy()
| void rigidbody::KalmanRecons::DeepCopy | ( | const KalmanRecons & | other | ) |
Deep copy of Kalman reconstruction.
- Parameters
-
other The Kalman reconstruction to copy
Definition at line 40 of file KalmanRecons.cpp.
◆ evolutionMatrix()
|
protected |
Create the evolution matrix.
- Parameters
-
m The number of degrees of freedom n The order of the Taylor development Te Is equal to \(\frac{1}{\text{Acquisition frequency}}\)
- Returns
- The evolution matrix assuming constant frame rate
Definition at line 102 of file KalmanRecons.cpp.
◆ getState()
| void rigidbody::KalmanRecons::getState | ( | rigidbody::GeneralizedCoordinates * | Q = nullptr, |
| rigidbody::GeneralizedVelocity * | Qdot = nullptr, | ||
| rigidbody::GeneralizedAcceleration * | Qddot = nullptr ) |
Get the state (Q, Qdot, Qddot).
- Parameters
-
Q The generalized coordinates Qdot The generalized velocities Qddot The generalized accelerations
Definition at line 84 of file KalmanRecons.cpp.
◆ initCovariance()
|
protected |
Returns a initialized covianriance matrix.
- Parameters
-
nbQ The number of degrees-of-freedom val The initial value to fill the matrix with
- Returns
- The initial covariance matrix
Definition at line 201 of file KalmanRecons.cpp.
◆ initialize()
|
protectedvirtual |
Initialization of the filter.
Reimplemented in BIORBD_NAMESPACE::rigidbody::KalmanReconsMarkers.
Definition at line 152 of file KalmanRecons.cpp.
◆ initState()
|
protected |
Initialize the states.
- Parameters
-
nbQ The number of degrees-of-freedom
- Returns
- The initialized states
Definition at line 179 of file KalmanRecons.cpp.
◆ iteration()
|
protected |
Compute an iteration of the Kalman filter.
- Parameters
-
measure The vector actual measurement to track projectedMeasure The projected measurement from the update step of the filter Hessian The hessian matrix occlusion The vector where occlusionsoccurs
Definition at line 52 of file KalmanRecons.cpp.
◆ manageOcclusionDuringIteration()
|
protectedvirtual |
Manage the occlusion during the iteration.
- Parameters
-
InvTp The inverse of the Tp matrix measure The vector actual measurement to track occlusion The vector where occlusions occurs
Reimplemented in BIORBD_NAMESPACE::rigidbody::KalmanReconsIMU, and BIORBD_NAMESPACE::rigidbody::KalmanReconsMarkers.
Definition at line 72 of file KalmanRecons.cpp.
◆ measurementNoiseMatrix()
|
protected |
Matrix of the noise on the measurements.
- Parameters
-
nbT The number of measurements val The noise level
- Returns
- The matrix of the noise on the measurements
Definition at line 169 of file KalmanRecons.cpp.
◆ processNoiseMatrix()
|
protected |
Process the noise matrix.
- Parameters
-
nbQ The number of degrees-of-freedom Te Is equal to \(\frac{1}{\text{Acquisition frequency}}\)
- Returns
- The noise matrix
Definition at line 123 of file KalmanRecons.cpp.
◆ reconstructFrame()
|
pure virtual |
Proceed to one iteration of the Kalman filter.
Implemented in BIORBD_NAMESPACE::rigidbody::KalmanReconsIMU, and BIORBD_NAMESPACE::rigidbody::KalmanReconsMarkers.
◆ setInitState()
| void rigidbody::KalmanRecons::setInitState | ( | const GeneralizedCoordinates * | Q = nullptr, |
| const GeneralizedVelocity * | Qdot = nullptr, | ||
| const GeneralizedAcceleration * | Qddot = nullptr ) |
Set the initial guess of the reconstruction.
- Parameters
-
Q The generalized coordinates Qdot The generalized velocities Qddot The generalized accelerations
Definition at line 184 of file KalmanRecons.cpp.
Member Data Documentation
◆ m_A
|
protected |
Evolution matrix.
Definition at line 204 of file KalmanRecons.h.
◆ m_nbDof
|
protected |
Number of states.
Definition at line 199 of file KalmanRecons.h.
◆ m_nMeasure
|
protected |
Number of measurements.
Definition at line 200 of file KalmanRecons.h.
◆ m_params
|
protected |
The parameters of the Kalman filter.
Definition at line 197 of file KalmanRecons.h.
◆ m_Pp
|
protected |
Covariance matrix.
Definition at line 208 of file KalmanRecons.h.
◆ m_Q
|
protected |
Noise matrix.
Definition at line 205 of file KalmanRecons.h.
◆ m_R
|
protected |
Matrix of the noise on the measurements.
Definition at line 207 of file KalmanRecons.h.
◆ m_Te
|
protected |
Inherent parameter to the frequency.
Definition at line 198 of file KalmanRecons.h.
◆ m_xp
|
protected |
State vector.
Definition at line 203 of file KalmanRecons.h.
The documentation for this class was generated from the following files:
