Loading...
Searching...
No Matches
BIORBD_NAMESPACE::rigidbody::KalmanReconsMarkers Class Reference
Class Kinematic reconstruction algorithm using an Extended Kalman Filter using skin markers. More...
#include <KalmanReconsMarkers.h>
Inheritance diagram for BIORBD_NAMESPACE::rigidbody::KalmanReconsMarkers:
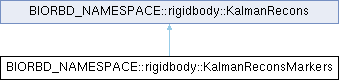
Public Member Functions | |
| KalmanReconsMarkers () | |
| Initialize the Kalman filter and Kalman reconstruction for Markers data. | |
| KalmanReconsMarkers (Model &model, KalmanParam params=KalmanParam()) | |
| Initialize the Kalman filter and Kalman reconstruction for Markers data. | |
| KalmanReconsMarkers | DeepCopy () const |
| Deep copy of the Kalman reconstruction. | |
| void | DeepCopy (const KalmanReconsMarkers &other) |
| Deep copy of the Kalman reconstruction. | |
| virtual void | reconstructFrame (Model &model, const Markers &Tobs, GeneralizedCoordinates *Q, GeneralizedVelocity *Qdot, GeneralizedAcceleration *Qddot, bool removeAxes=true) |
| Reconstruct the kinematics from markers data. | |
| virtual void | reconstructFrame (Model &model, const std::vector< NodeSegment > &Tobs, GeneralizedCoordinates *Q, GeneralizedVelocity *Qdot, GeneralizedAcceleration *Qddot, bool removeAxes=true) |
| Reconstruct the kinematics from markers data. | |
| virtual void | reconstructFrame (Model &model, const utils::Vector &Tobs, GeneralizedCoordinates *Q=nullptr, GeneralizedVelocity *Qdot=nullptr, GeneralizedAcceleration *Qddot=nullptr, bool removeAxes=true) |
| Reconstruct the kinematics from markers data. | |
| virtual void | reconstructFrame () |
| This function cannot be used to reconstruct frames. | |
| bool | first () |
| Return if the first iteration was done. | |
| Public Member Functions inherited from BIORBD_NAMESPACE::rigidbody::KalmanRecons | |
| KalmanRecons () | |
| Kalman reconstruction. | |
| KalmanRecons (Model &model, size_t nbMeasure, KalmanParam params=KalmanParam()) | |
| Kalman reconstruction. | |
| virtual | ~KalmanRecons () |
| Destroy class properly. | |
| void | DeepCopy (const KalmanRecons &other) |
| Deep copy of Kalman reconstruction. | |
| void | getState (GeneralizedCoordinates *Q=nullptr, GeneralizedVelocity *Qdot=nullptr, GeneralizedAcceleration *Qddot=nullptr) |
| Get the state (Q, Qdot, Qddot). | |
| void | setInitState (const GeneralizedCoordinates *Q=nullptr, const GeneralizedVelocity *Qdot=nullptr, const GeneralizedAcceleration *Qddot=nullptr) |
| Set the initial guess of the reconstruction. | |
Protected Member Functions | |
| virtual void | initialize () |
| Initialization of the filter. | |
| virtual void | manageOcclusionDuringIteration (utils::Matrix &InvTp, utils::Vector &measure, const std::vector< size_t > &occlusion) |
| Manage the occlusion during the iteration. | |
| Protected Member Functions inherited from BIORBD_NAMESPACE::rigidbody::KalmanRecons | |
| utils::Matrix | evolutionMatrix (const size_t m, size_t n, double Te) |
| Create the evolution matrix. | |
| utils::Matrix | processNoiseMatrix (const size_t nbQ, double Te) |
| Process the noise matrix. | |
| utils::Matrix | measurementNoiseMatrix (const size_t nbT, double val) |
| Matrix of the noise on the measurements. | |
| utils::Matrix | initCovariance (const size_t nbQ, double val) |
| Returns a initialized covianriance matrix. | |
| GeneralizedCoordinates | initState (const size_t nbQ) |
| Initialize the states. | |
| void | iteration (utils::Vector measure, const utils::Vector &projectedMeasure, const utils::Matrix &Hessian, const std::vector< size_t > &occlusion=std::vector< size_t >()) |
| Compute an iteration of the Kalman filter. | |
Protected Attributes | |
| std::shared_ptr< utils::Matrix > | m_PpInitial |
| Initial covariance matrix. | |
| std::shared_ptr< bool > | m_firstIteration |
| If first iteration was done. | |
| Protected Attributes inherited from BIORBD_NAMESPACE::rigidbody::KalmanRecons | |
| std::shared_ptr< KalmanParam > | m_params |
| The parameters of the Kalman filter. | |
| std::shared_ptr< double > | m_Te |
| Inherent parameter to the frequency. | |
| std::shared_ptr< size_t > | m_nbDof |
| Number of states. | |
| std::shared_ptr< size_t > | m_nMeasure |
| Number of measurements. | |
| std::shared_ptr< utils::Vector > | m_xp |
| State vector. | |
| std::shared_ptr< utils::Matrix > | m_A |
| Evolution matrix. | |
| std::shared_ptr< utils::Matrix > | m_Q |
| Noise matrix. | |
| std::shared_ptr< utils::Matrix > | m_R |
| Matrix of the noise on the measurements. | |
| std::shared_ptr< utils::Matrix > | m_Pp |
| Covariance matrix. | |
Detailed Description
Class Kinematic reconstruction algorithm using an Extended Kalman Filter using skin markers.
Definition at line 17 of file KalmanReconsMarkers.h.
Constructor & Destructor Documentation
◆ KalmanReconsMarkers() [1/2]
| rigidbody::KalmanReconsMarkers::KalmanReconsMarkers | ( | ) |
Initialize the Kalman filter and Kalman reconstruction for Markers data.
Definition at line 20 of file KalmanReconsMarkers.cpp.
◆ KalmanReconsMarkers() [2/2]
| rigidbody::KalmanReconsMarkers::KalmanReconsMarkers | ( | Model & | model, |
| rigidbody::KalmanParam | params = KalmanParam() ) |
Initialize the Kalman filter and Kalman reconstruction for Markers data.
- Parameters
-
model The joint model params The Kalman filter parameters
Definition at line 25 of file KalmanReconsMarkers.cpp.
Member Function Documentation
◆ DeepCopy() [1/2]
| rigidbody::KalmanReconsMarkers rigidbody::KalmanReconsMarkers::DeepCopy | ( | ) | const |
Deep copy of the Kalman reconstruction.
- Returns
- Copy of the Kalman reconstruction
Definition at line 35 of file KalmanReconsMarkers.cpp.
◆ DeepCopy() [2/2]
| void rigidbody::KalmanReconsMarkers::DeepCopy | ( | const KalmanReconsMarkers & | other | ) |
Deep copy of the Kalman reconstruction.
- Parameters
-
other The Kalman reconstruction to copy
Definition at line 42 of file KalmanReconsMarkers.cpp.
◆ first()
| bool rigidbody::KalmanReconsMarkers::first | ( | ) |
Return if the first iteration was done.
- Returns
- If the first iteration was done
Definition at line 68 of file KalmanReconsMarkers.cpp.
◆ initialize()
|
protectedvirtual |
Initialization of the filter.
Reimplemented from BIORBD_NAMESPACE::rigidbody::KalmanRecons.
Definition at line 49 of file KalmanReconsMarkers.cpp.
◆ manageOcclusionDuringIteration()
|
protectedvirtual |
Manage the occlusion during the iteration.
- Parameters
-
InvTp The inverse of the Tp matrix measure The vector actual measurement to track occlusion The vector where occlusions occurs
Reimplemented from BIORBD_NAMESPACE::rigidbody::KalmanRecons.
Definition at line 56 of file KalmanReconsMarkers.cpp.
◆ reconstructFrame() [1/4]
|
virtual |
This function cannot be used to reconstruct frames.
Implements BIORBD_NAMESPACE::rigidbody::KalmanRecons.
Definition at line 192 of file KalmanReconsMarkers.cpp.
◆ reconstructFrame() [2/4]
|
virtual |
Reconstruct the kinematics from markers data.
- Parameters
-
model The joint model Tobs The observed markers Q The generalized coordinates Qdot The generalized velocities Qddot The generalized accelerations removeAxes If the algo should ignore or not the removeAxis defined in the bioMod file
Definition at line 70 of file KalmanReconsMarkers.cpp.
◆ reconstructFrame() [3/4]
|
virtual |
Reconstruct the kinematics from markers data.
- Parameters
-
model The joint model Tobs The observed markers Q The generalized coordinates Qdot The generalized velocities Qddot The generalized accelerations removeAxes If the algo should ignore or not the removeAxis defined in the bioMod file
Definition at line 87 of file KalmanReconsMarkers.cpp.
◆ reconstructFrame() [4/4]
|
virtual |
Reconstruct the kinematics from markers data.
- Parameters
-
model The joint model Tobs The observed markers in a column-major vector Q The generalized coordinates Qdot The generalized velocities Qddot The generalized accelerations removeAxes If the algo should ignore or not the removeAxis defined in the bioMod file
Definition at line 104 of file KalmanReconsMarkers.cpp.
Member Data Documentation
◆ m_firstIteration
|
protected |
If first iteration was done.
Definition at line 130 of file KalmanReconsMarkers.h.
◆ m_PpInitial
|
protected |
Initial covariance matrix.
Definition at line 129 of file KalmanReconsMarkers.h.
The documentation for this class was generated from the following files:
